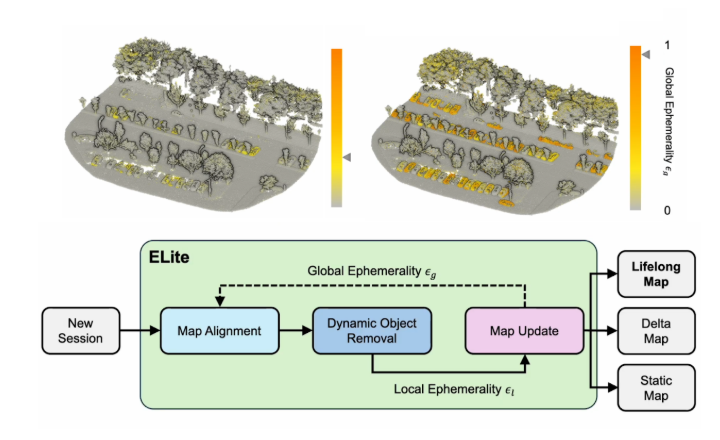
Publications/Patents

updated Sep 23, 2026

Author notes* First/co-first author† Corresponding authorbold APRL member
Region
Type
APRL*†
Range
View
Filtered results: 30 of 49 publications
Publication Year
Venue
Selected
Others (A-Z)
2026
2026InternationalConferenceAPRL

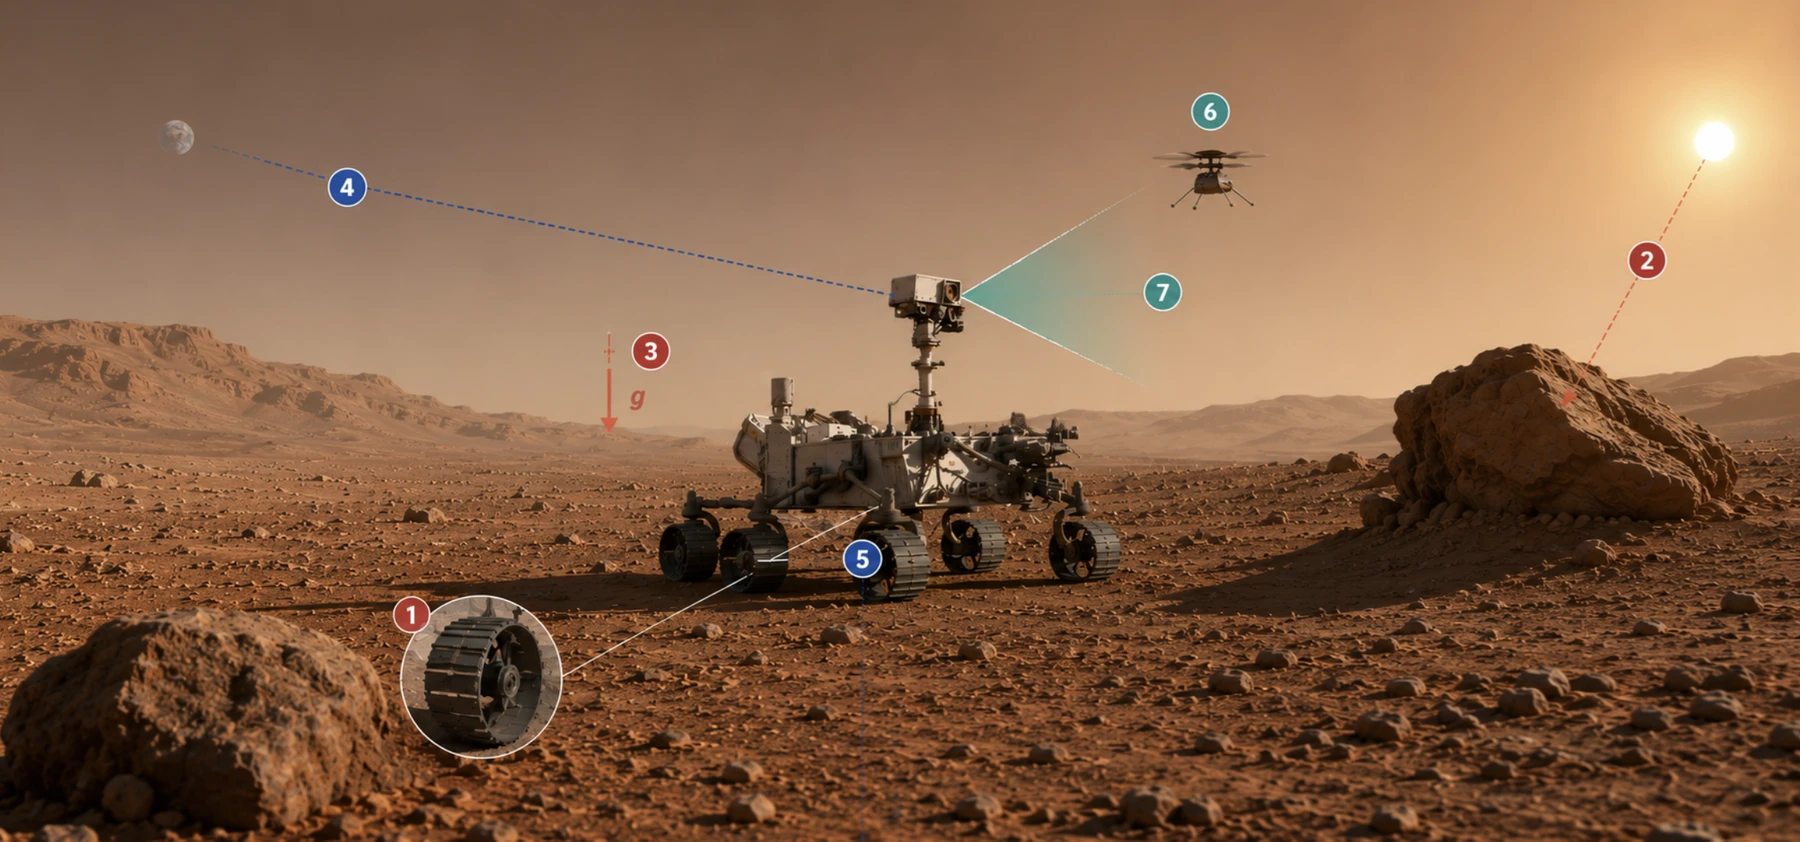
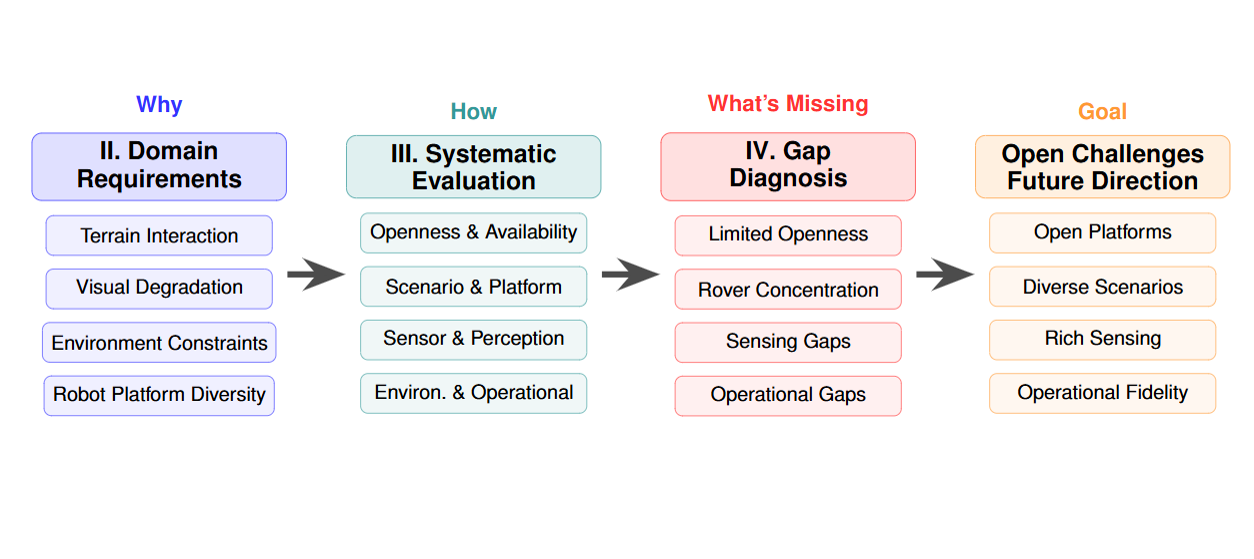
Simulation for Planetary Robotic Perception and Autonomy: A Concise Survey of Recent Capabilities and Gaps

Venue/BookInternational Conference on Space Robotics (iSpaRo)DateNov 3-6, 2026AuthorsHoyun Kim*, Giseop Kim†Noteaccepted, to appear
Planetary robotics simulation overview showing a Mars rover, terrain interaction, lighting, gravity, communication, aerial robotics, and perception
2026InternationalPreprintAPRL

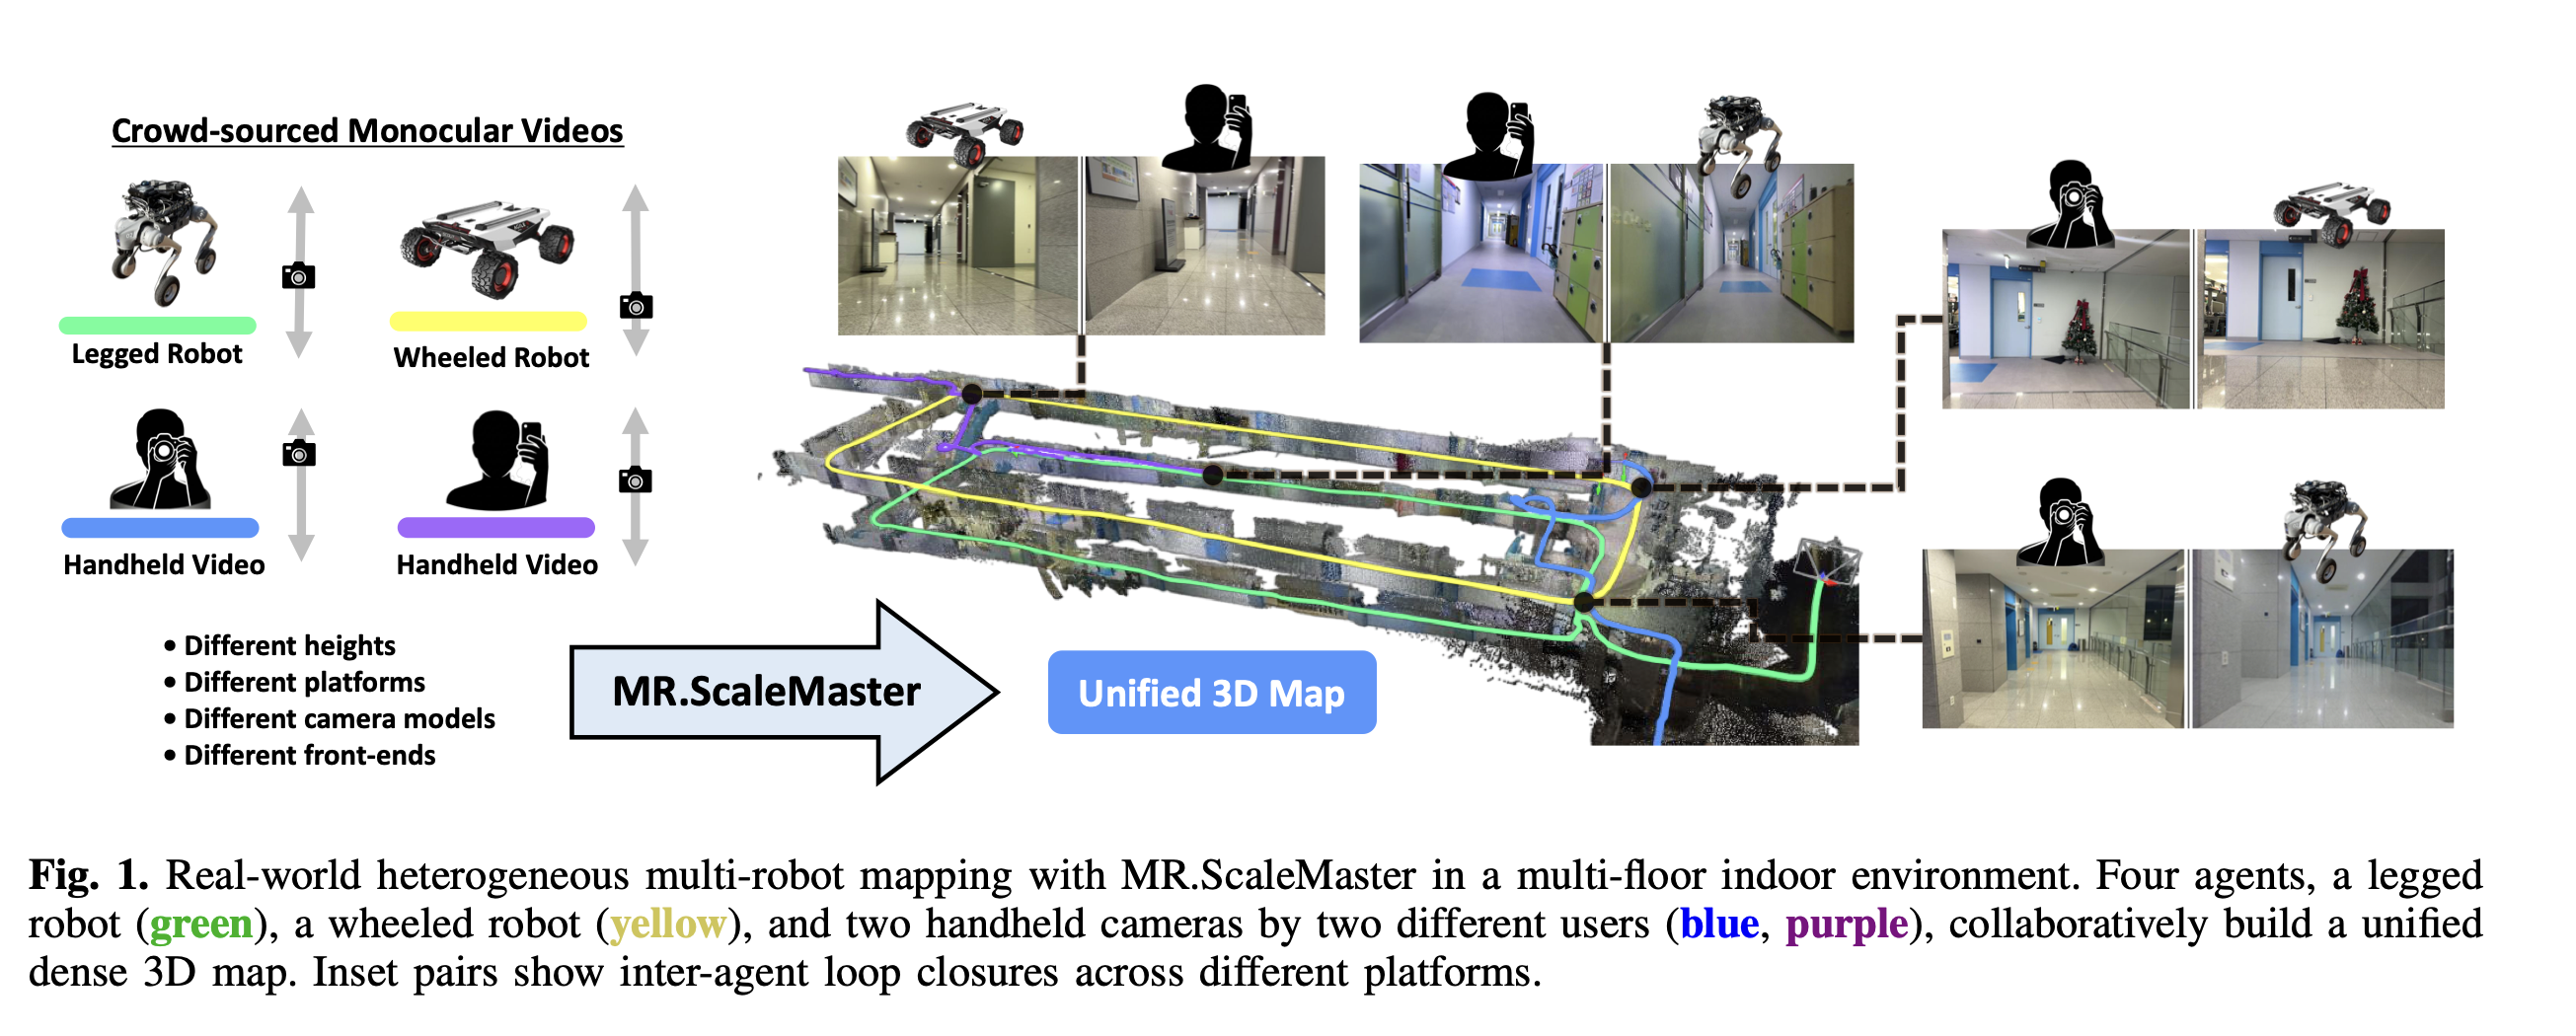
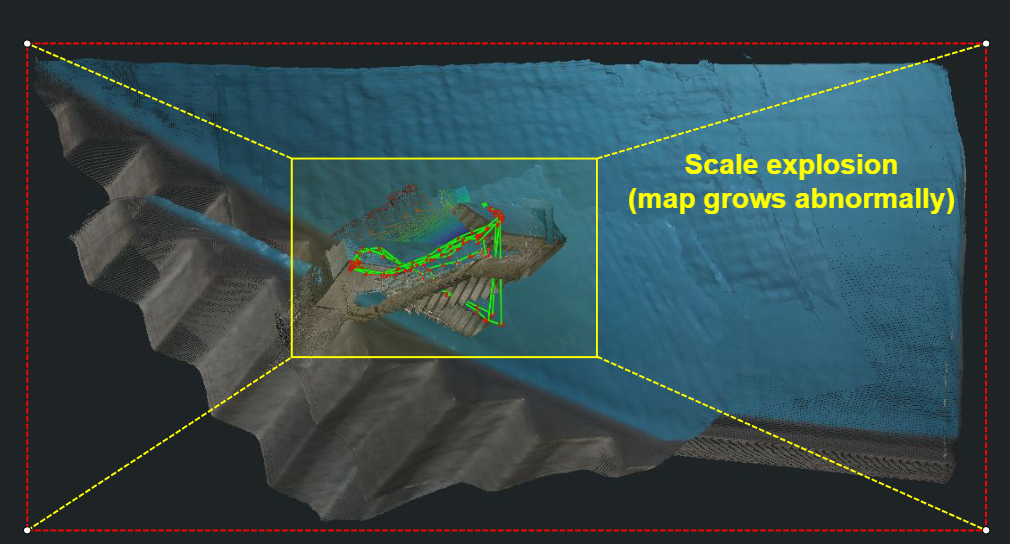
MR.ScaleMaster: Scale-Consistent Collaborative Mapping from Crowd-Sourced Monocular Videos

Venue/BookarXiv preprintDateSep 23, 2026AuthorsHyoseok Ju*, Giseop Kim†
Figure for MR.ScaleMaster: Scale-Consistent Collaborative Mapping from Crowd-Sourced Monocular Videos
2026InternationalPreprintAPRL

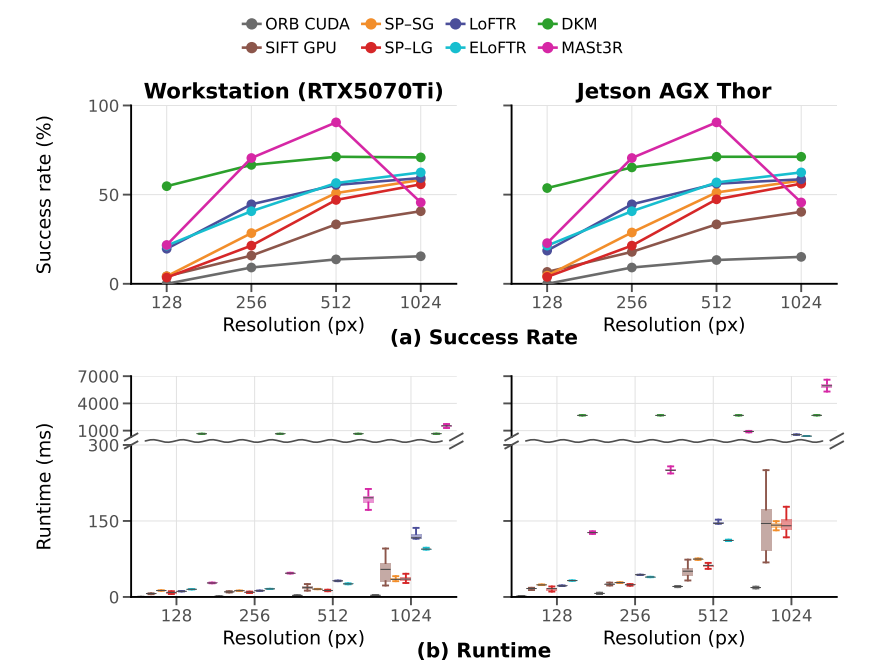
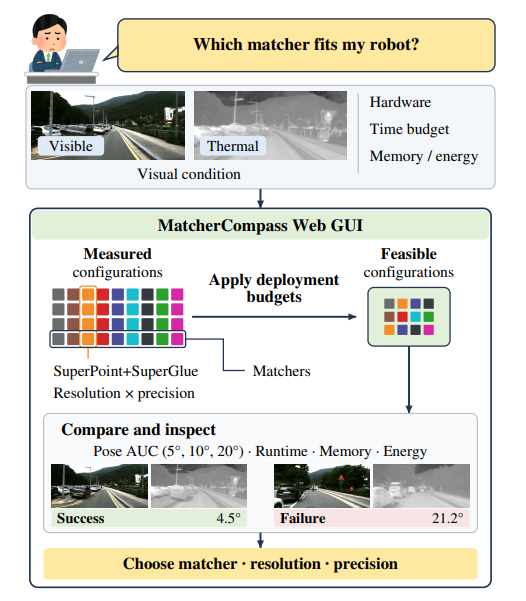
MatcherCompass: A Deployment-Aware Benchmark to Guide Image Matcher Selection in the Wild

Venue/BookarXiv preprintDateSep 22, 2026AuthorsHyunwoo Kim*, Giseop Kim†NoteThis work was conducted during Hyunwoo Kim’s internship at APRL.
MatcherCompass workflow: select visual conditions and hardware, apply deployment budgets, compare pose accuracy and resource use, and choose a matcher configuration
2026InternationalConferenceAPRL

Venue/Book23rd IFAC World CongressDateAug 23-28, 2026AuthorsBokeon Suh*, Hyoseok Ju, Giseop Kim†
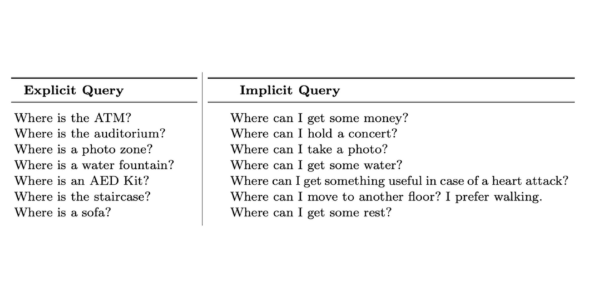
Figure for What Matters for Real-World Long-Horizon Robot Navigation?: An Experimental Study of Implicit Goals and Sparse Memory
2026InternationalPreprintAPRL

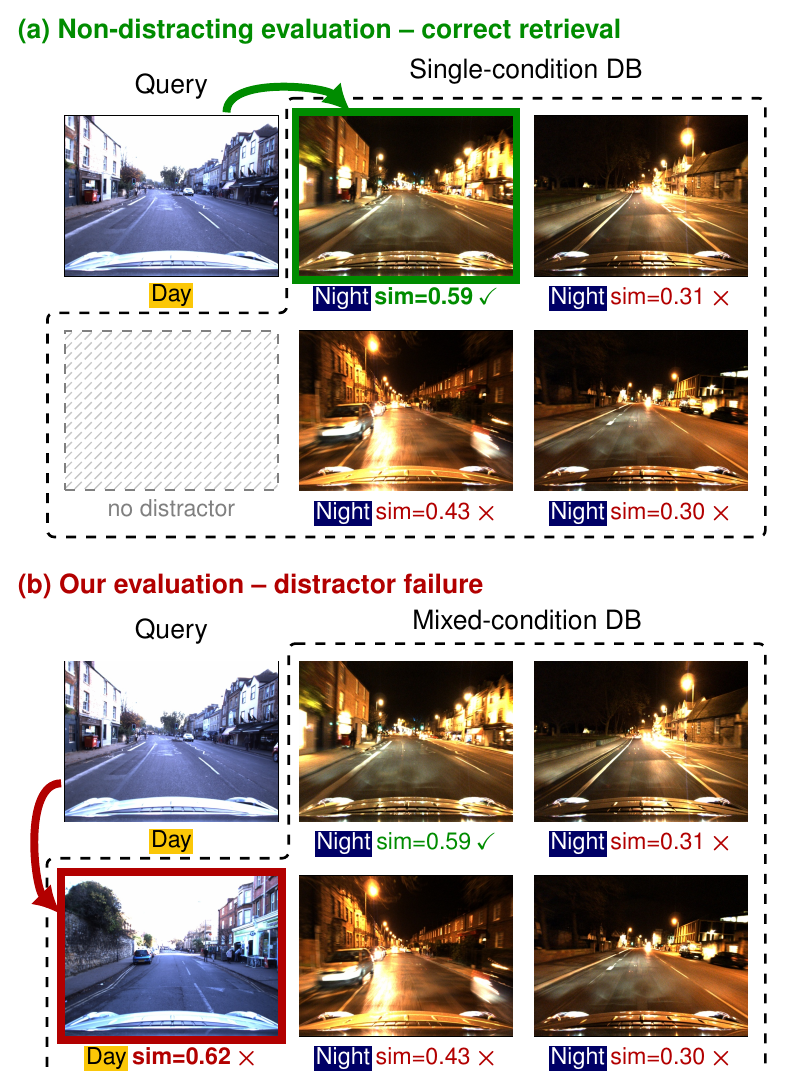
Are Visual Place Recognition Models Recognizing Places or Conditions? Distractor-Augmented Evaluation and Condition Suppression

Venue/BookarXiv preprintDateAug 7, 2026AuthorsBeomsu Kim*, Minwoo Jung, Giseop Kim†CollaborationSNU
Distractor-augmented evaluation reveals condition-biased visual place recognition
2026InternationalConference

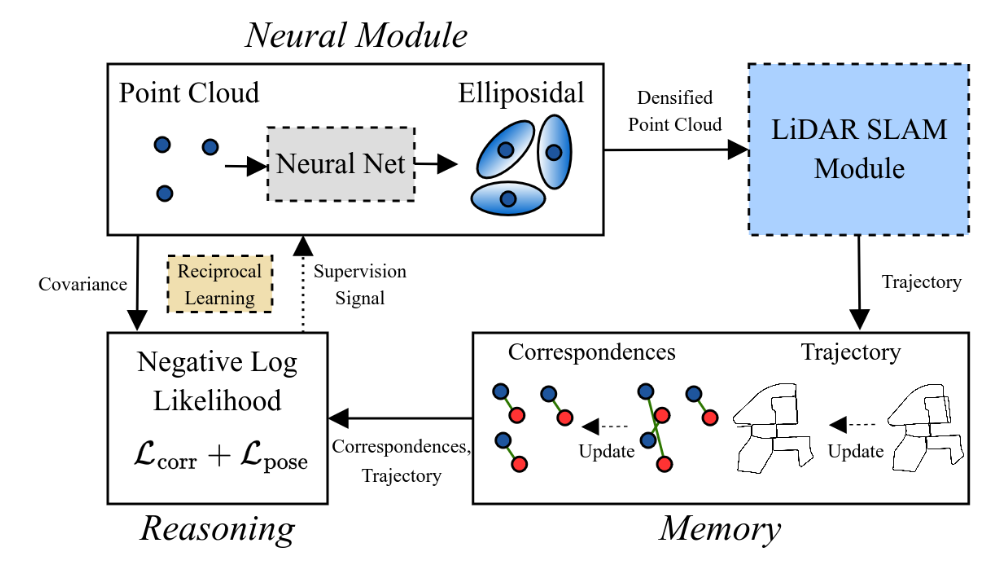
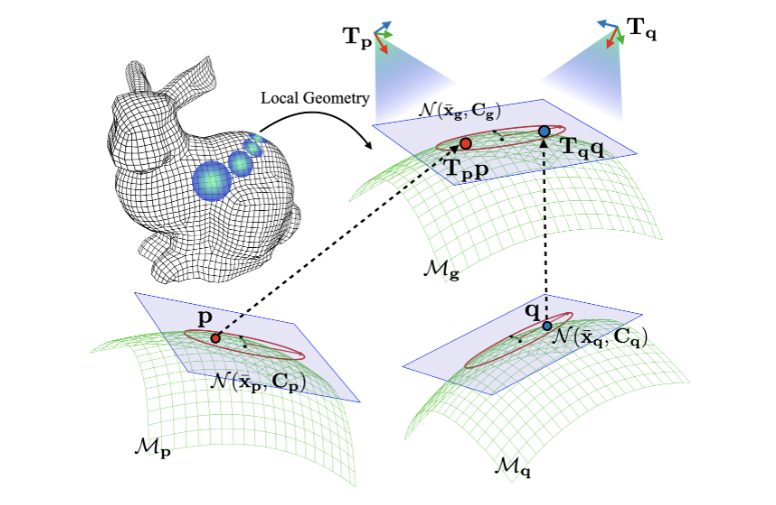
Learning Point Cloud Geometry as a Statistical Manifold: Theory and Practice

Venue/BookRobotics: Science and Systems (RSS)DateJul 13-17, 2026AuthorsJinwoo Lee*, Jiwoo Kim*, WooJae Shin, Giseop Kim, Hyondong Oh†CollaborationKAIST
Figure for Learning Point Cloud Geometry as a Statistical Manifold: Theory and Practice
2026DomesticConferenceAPRL

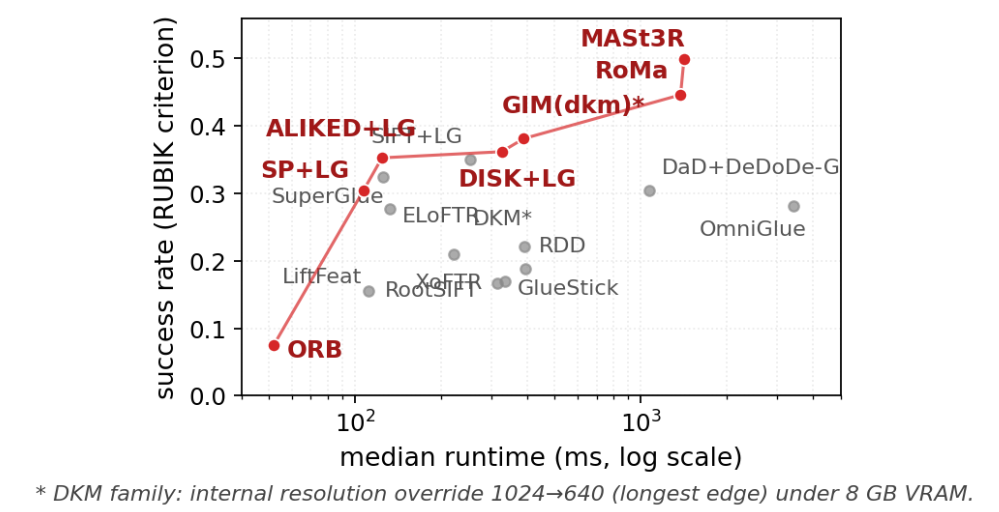
RUBIK 기반 18개 image matcher의 geometrical 강건성 및 속도-정확도 Pareto Frontier 분석

Venue/BookInstitute of Control, Robotics and Systems (ICROS)DateJul 1-4, 2026Authors김현우*, 김기섭†Notenon-archival
Figure for RUBIK 기반 18개 image matcher의 geometrical 강건성 및 속도-정확도 Pareto Frontier 분석
2026DomesticConferenceAPRL

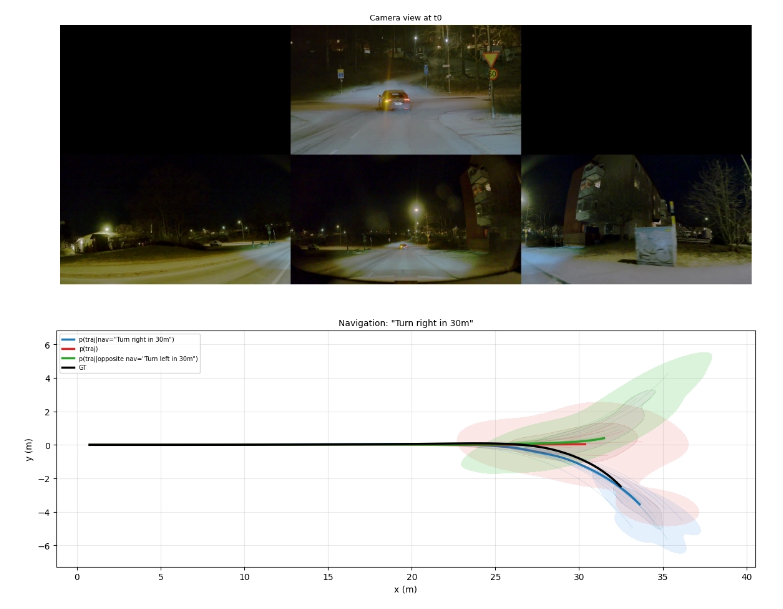
자율주행 VLA 모델 Alpamayo 1.5의 실내 환경 거동과 네비게이션 지시 응답

Venue/BookInstitute of Control, Robotics and Systems (ICROS)DateJul 1-4, 2026Authors이아윤*, 김기섭†Notenon-archival; Undergraduate Student Paper Award
Figure for 자율주행 VLA 모델 Alpamayo 1.5의 실내 환경 거동과 네비게이션 지시 응답
2026DomesticConferenceAPRL

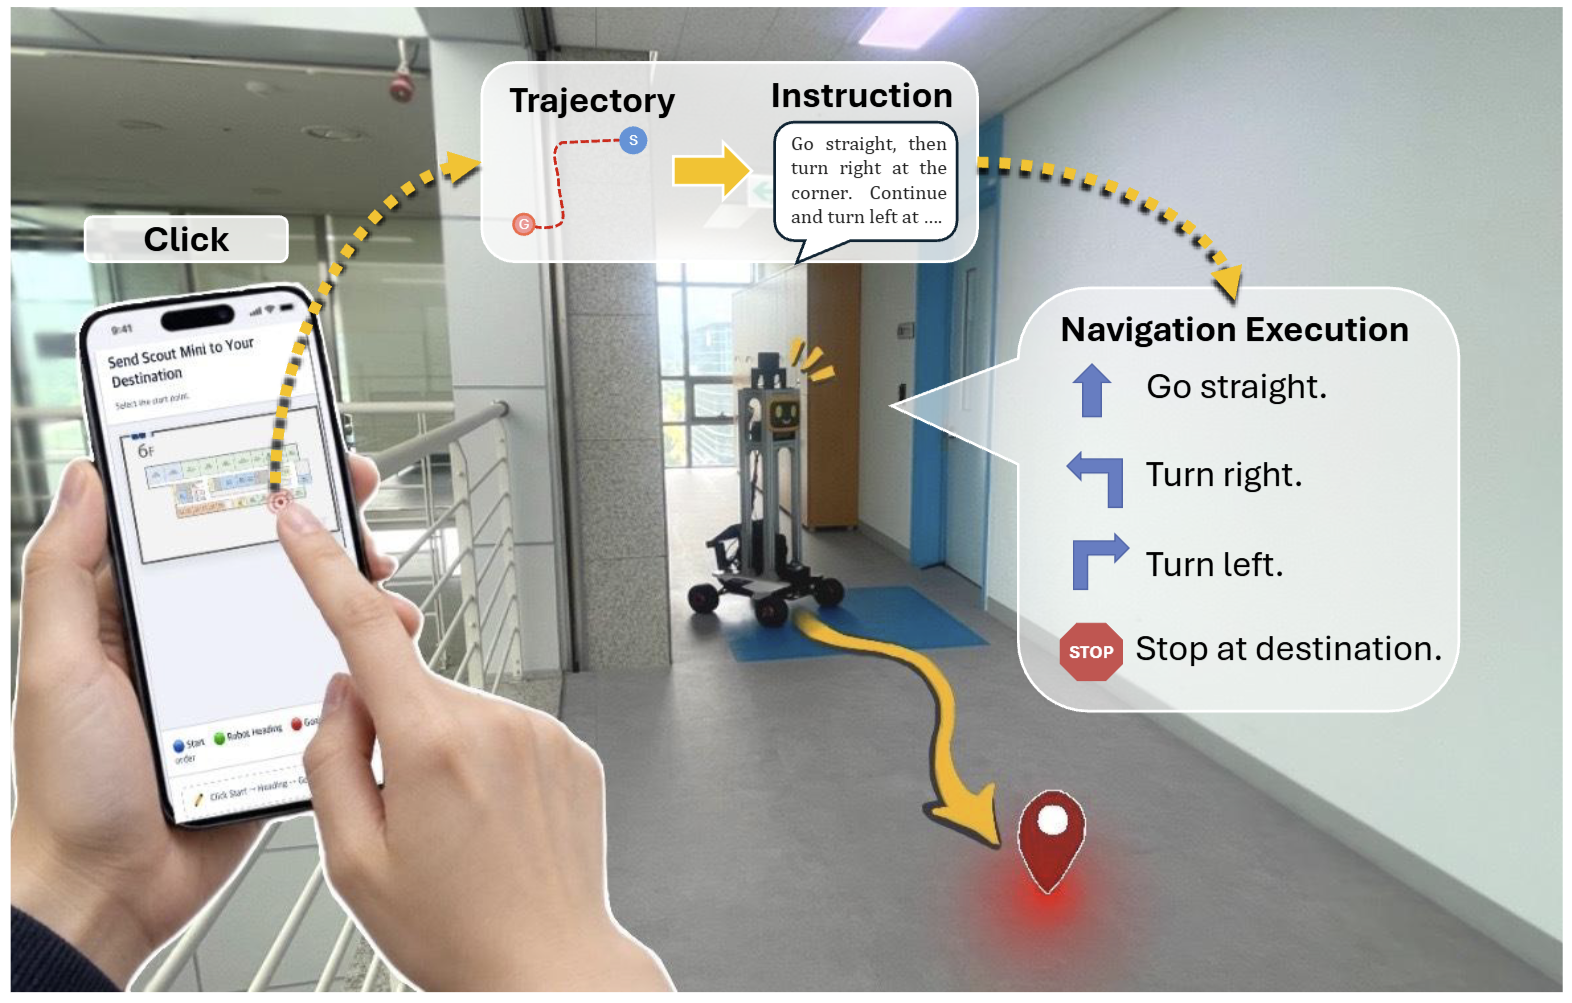
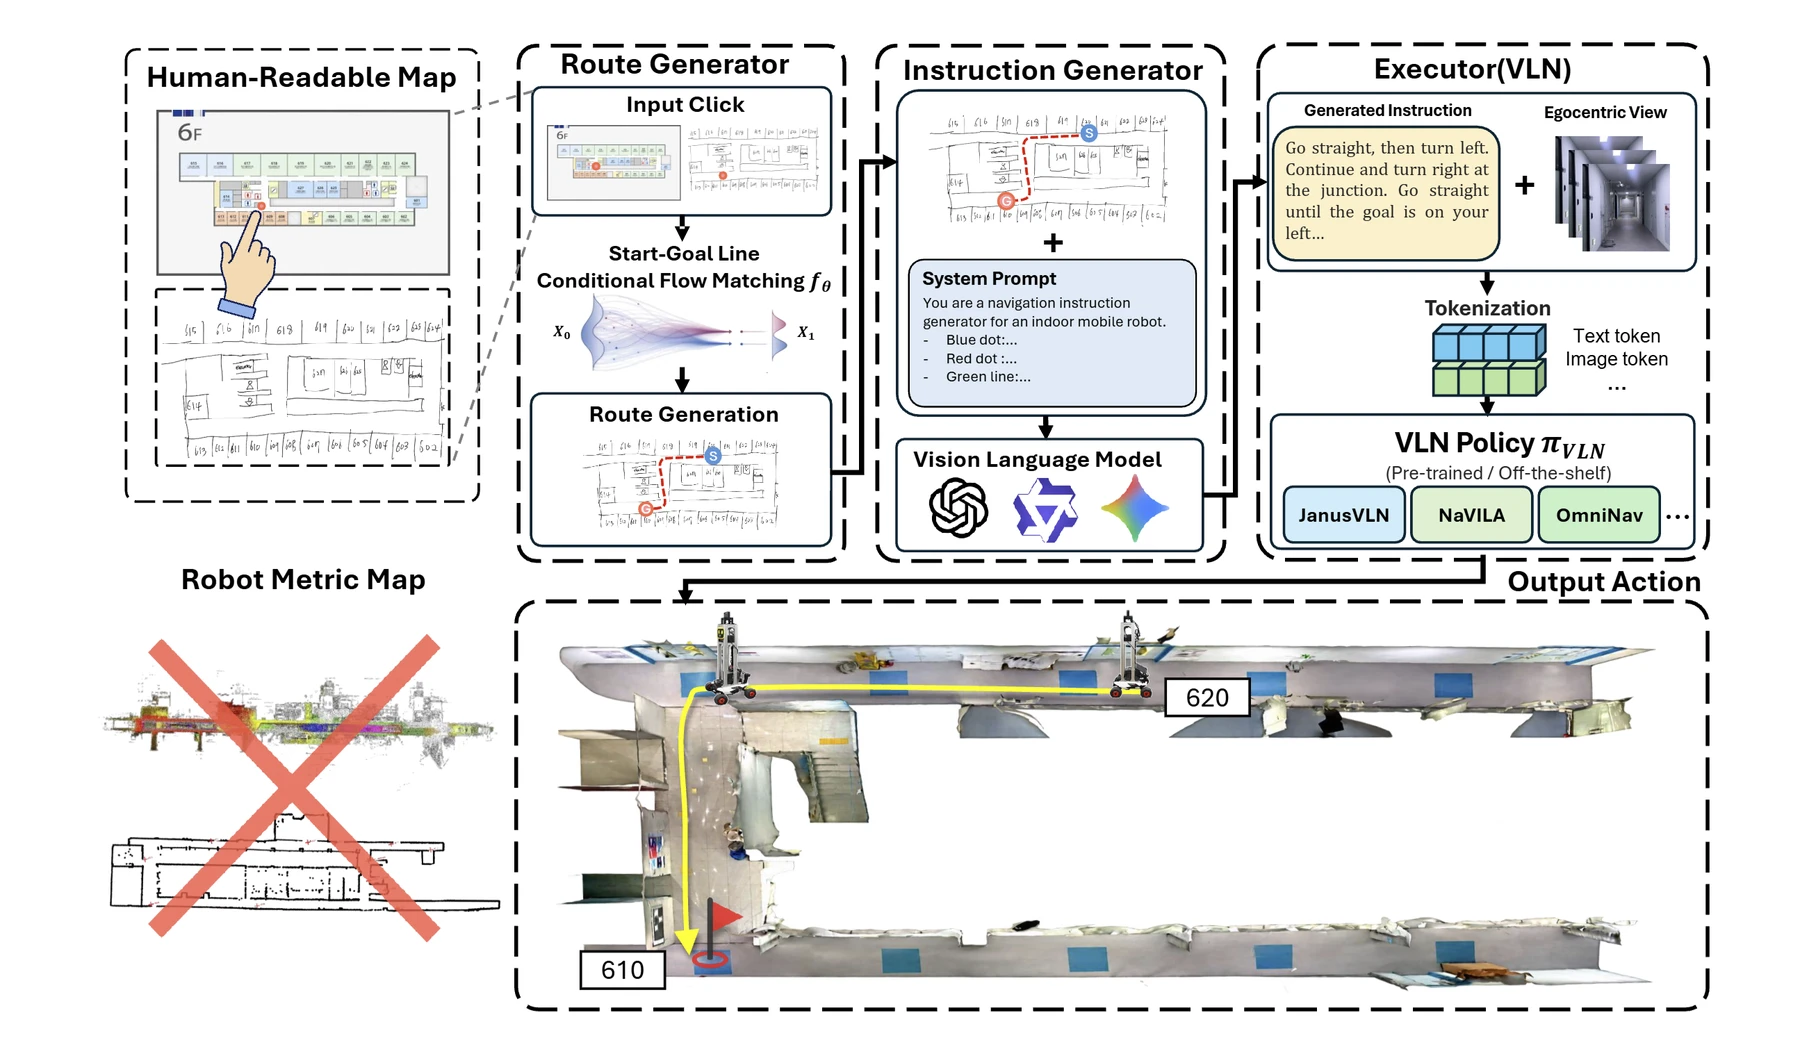
Floor Plan-Guided Point-to-Language Grounded Navigation
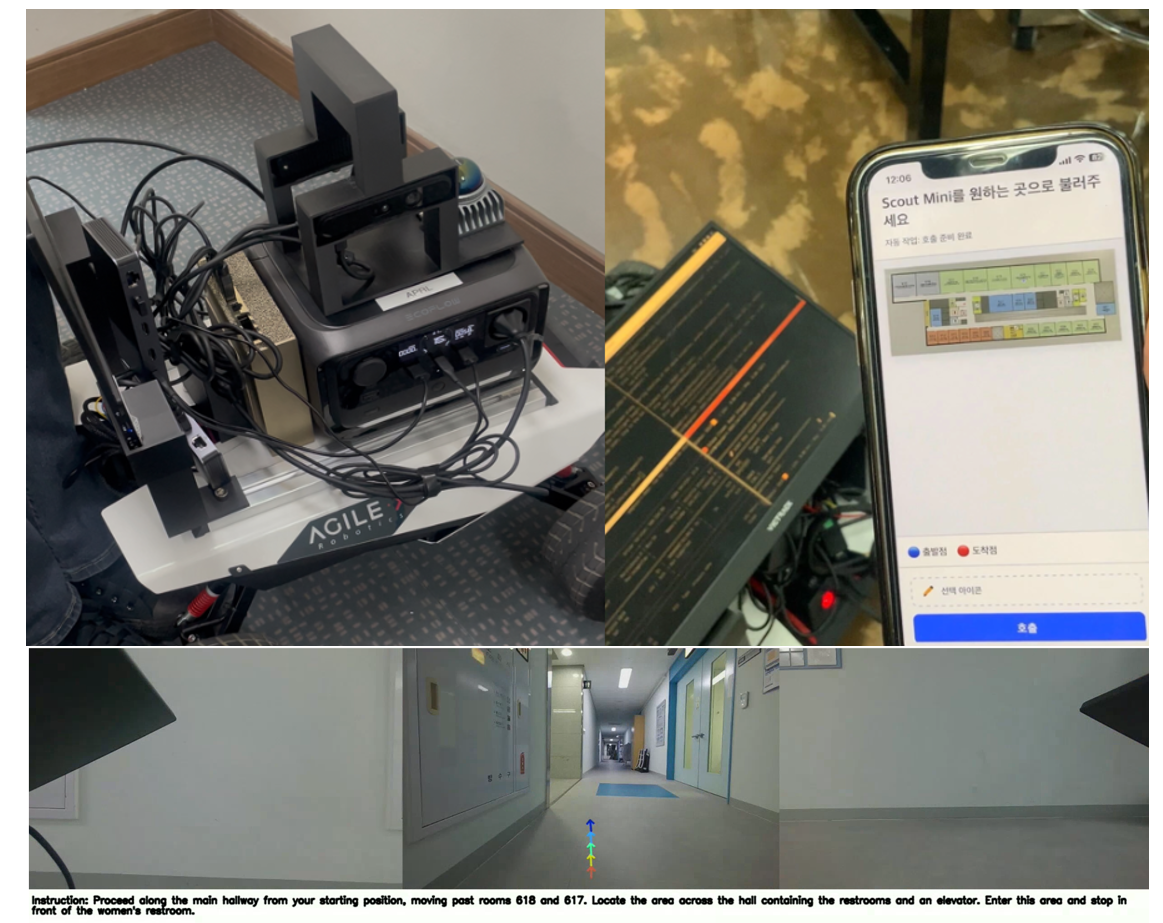
Venue/BookInstitute of Control, Robotics and Systems (ICROS)DateJul 1-4, 2026Authors이아윤*, 김기섭†
Figure for 평면도 기반 포인트−언어 그라운디드 네비게이션
2026DomesticConferenceAPRL

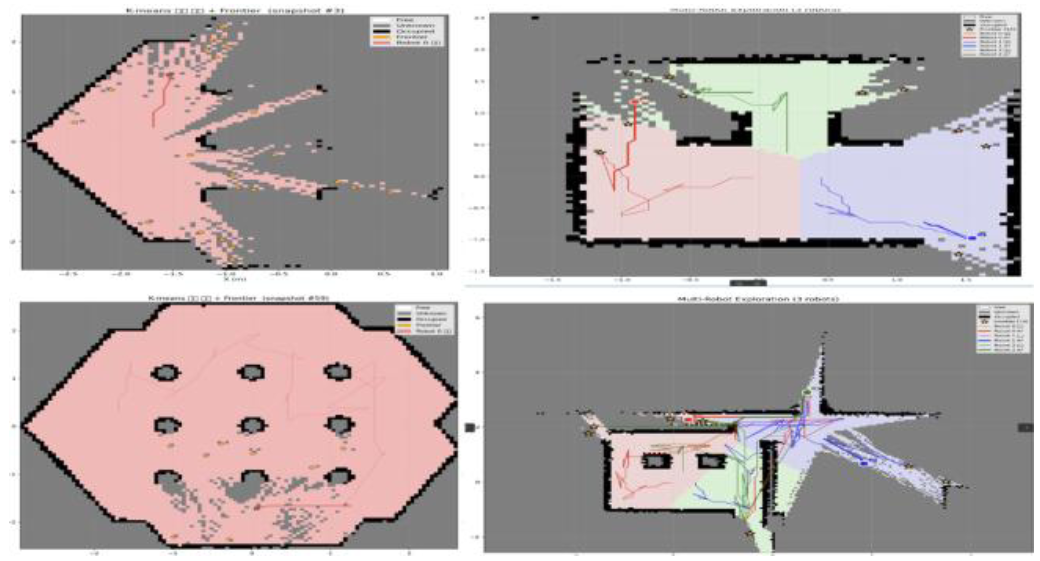
Venue/BookInstitute of Control, Robotics and Systems (ICROS)DateJul 1-4, 2026Authors이아윤*, 윤하경*, 박상혁*, 이민규*, 김기섭†NoteUGRP
Figure for 랑데부 브리핑: VLM 기반 의미 인식 멀티로봇 협력 탐사 기법
2026DomesticConferenceAPRL

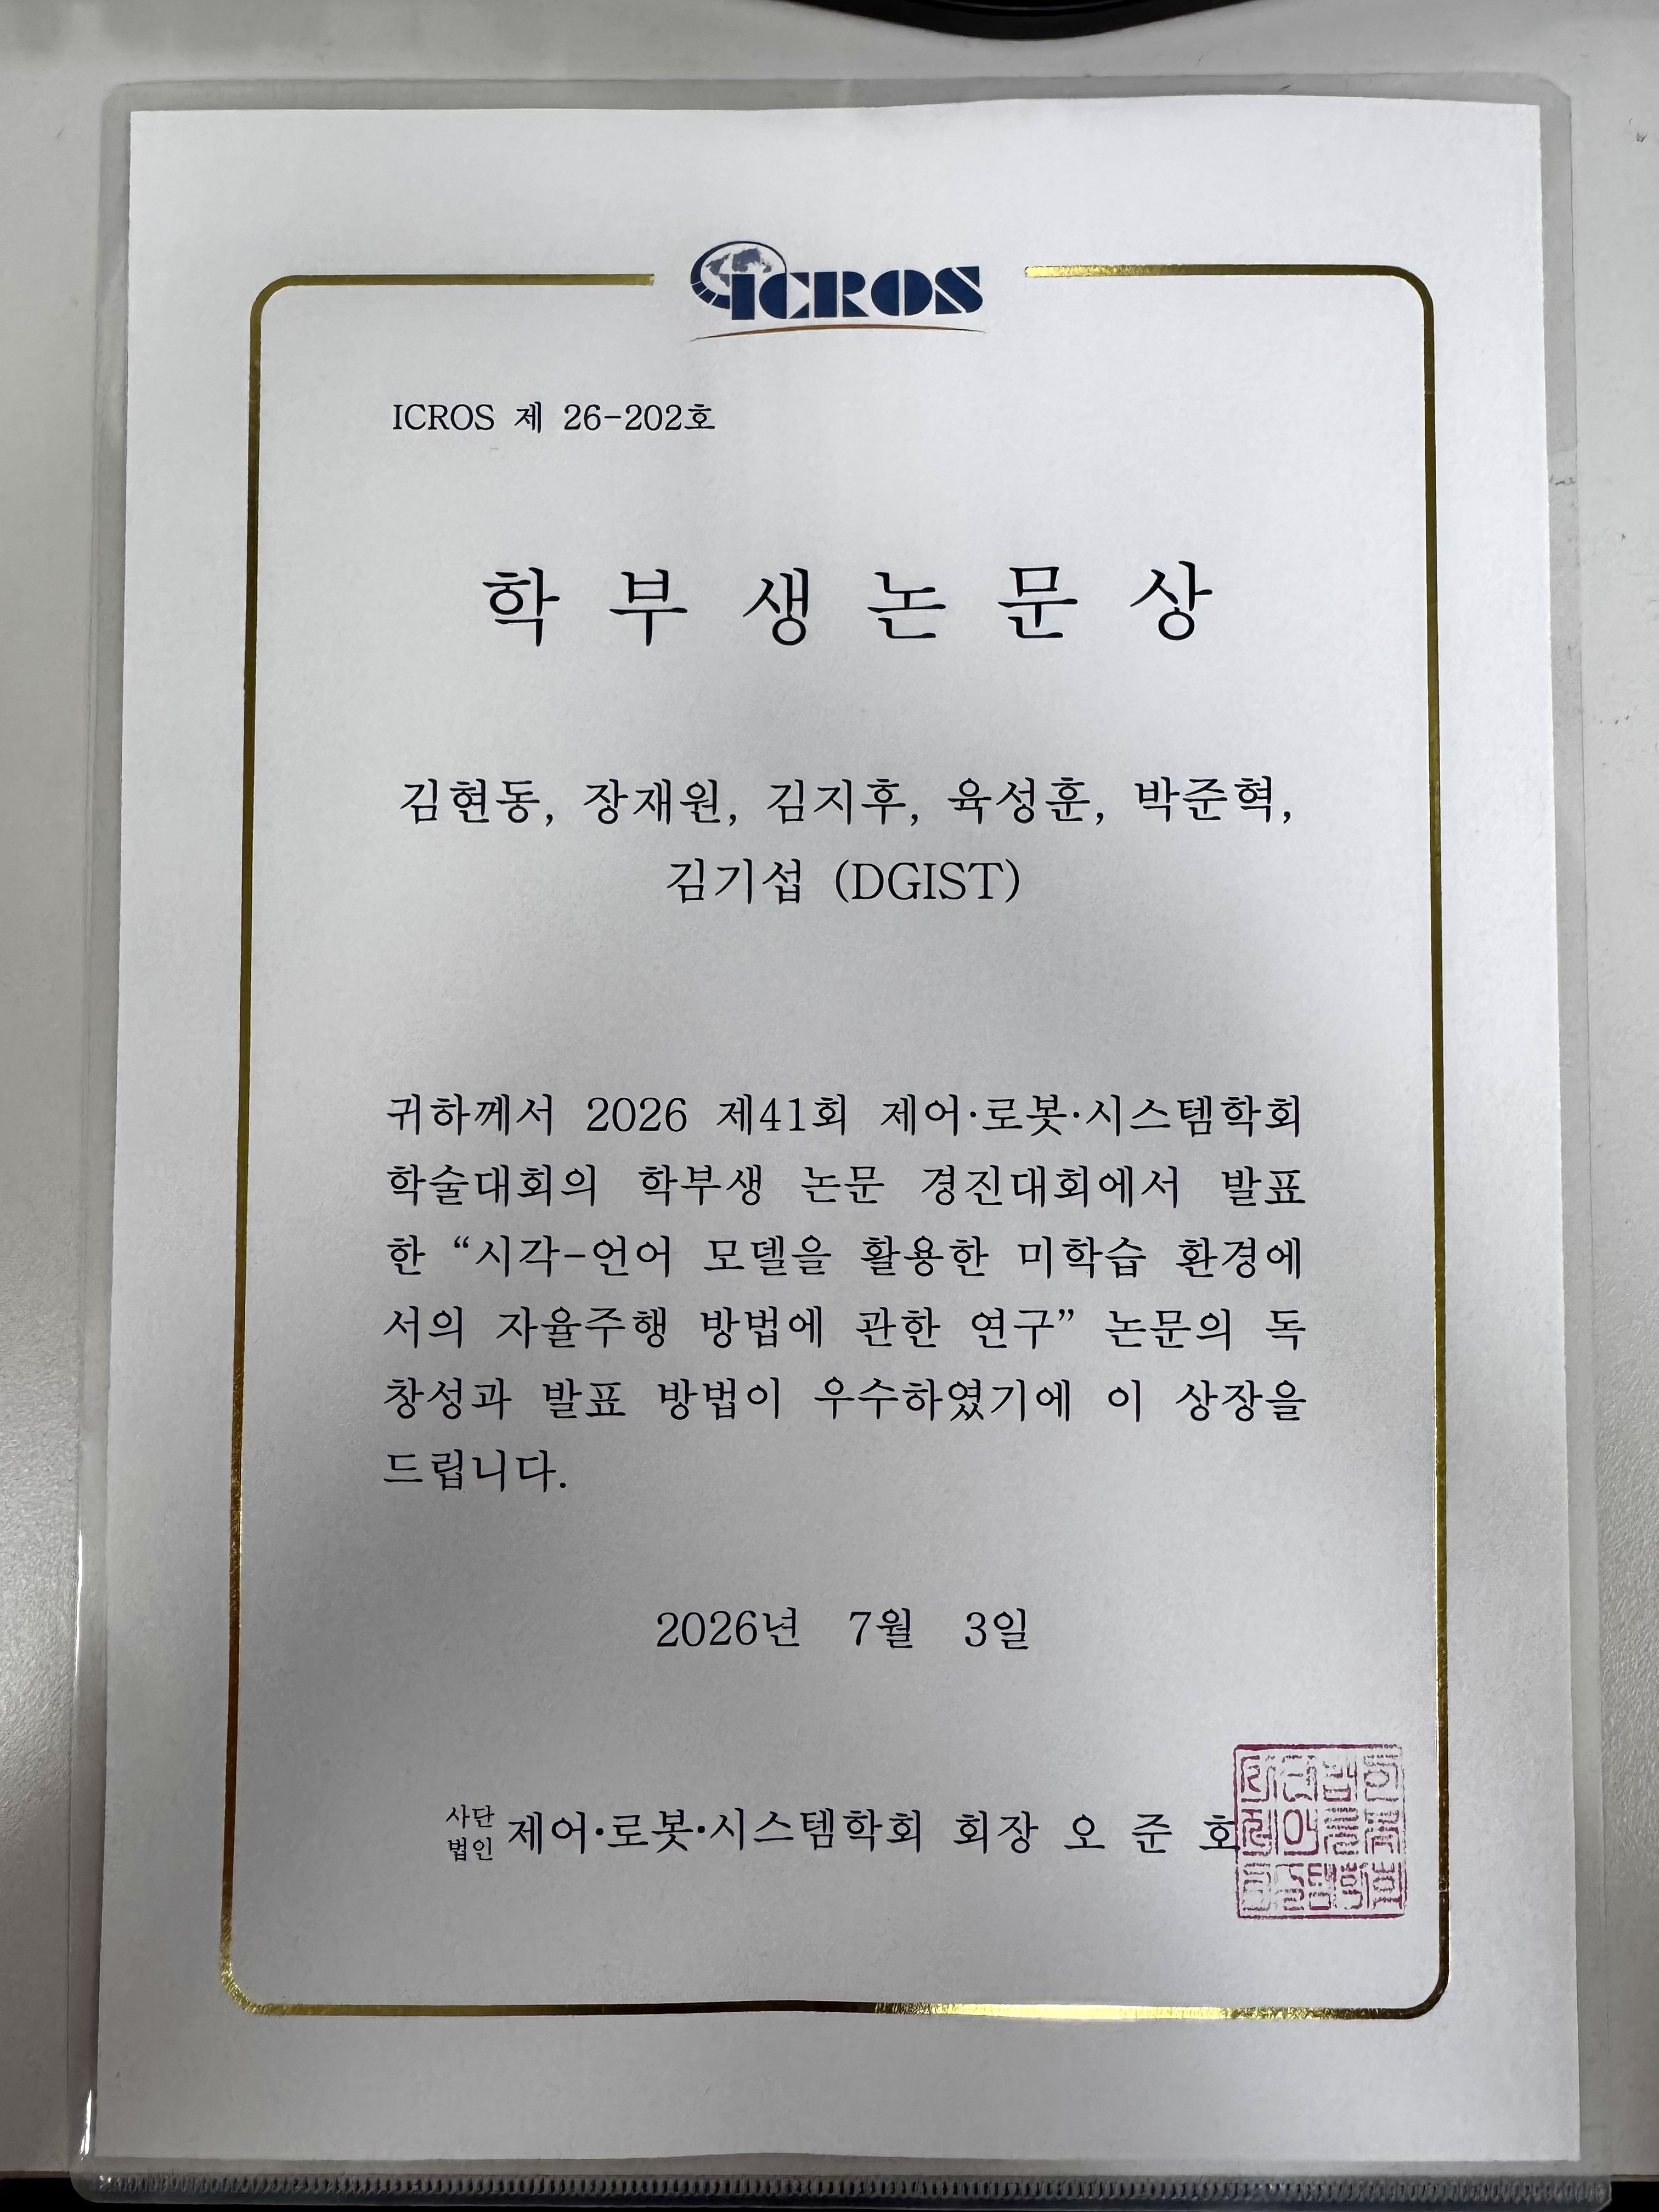
시각-언어 모델을 활용한 미학습 환경에서의 자율주행 방법에 관한 연구

Mapless Zero-Shot Autonomous Driving with Vision-Language Models
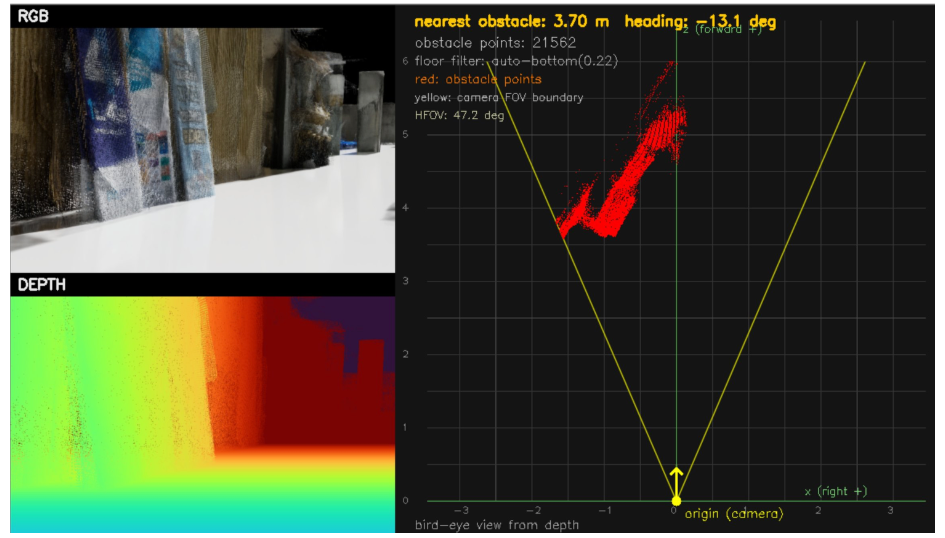
Venue/BookInstitute of Control, Robotics and Systems (ICROS)DateJul 1-4, 2026Authors김현동*, 장재원, 김지후, 육성훈, 박준혁, 김기섭†Notenon-archival; UGRP; Undergraduate Student Paper Award
Figure for 시각-언어 모델을 활용한 미학습 환경에서의 자율주행 방법에 관한 연구
2026DomesticConferenceAPRL

루빅스 큐브 메커니즘 기반 바퀴 전환형 이동 로봇

A Wheel-Transformable Mobile Robot Based on a Rubik’s Cube Mechanism
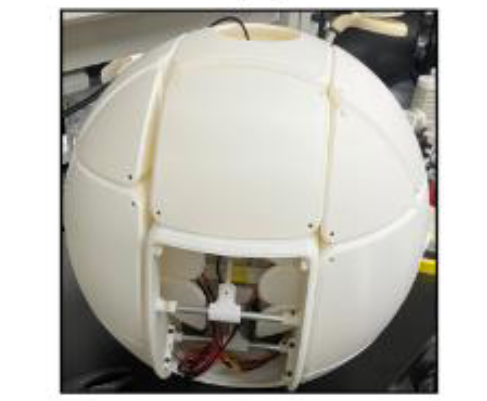
Venue/BookInstitute of Control, Robotics and Systems (ICROS)DateJul 1-4, 2026Authors육성훈*, 김지후, 장재원, 김현동, 김기섭, 박준혁†CollaborationWEAR lab @ DGISTNotenon-archival; UGRP; Undergraduate Student Paper Award
Figure for 루빅스 큐브 메커니즘 기반 바퀴 전환형 이동 로봇
2026InternationalWorkshopAPRL

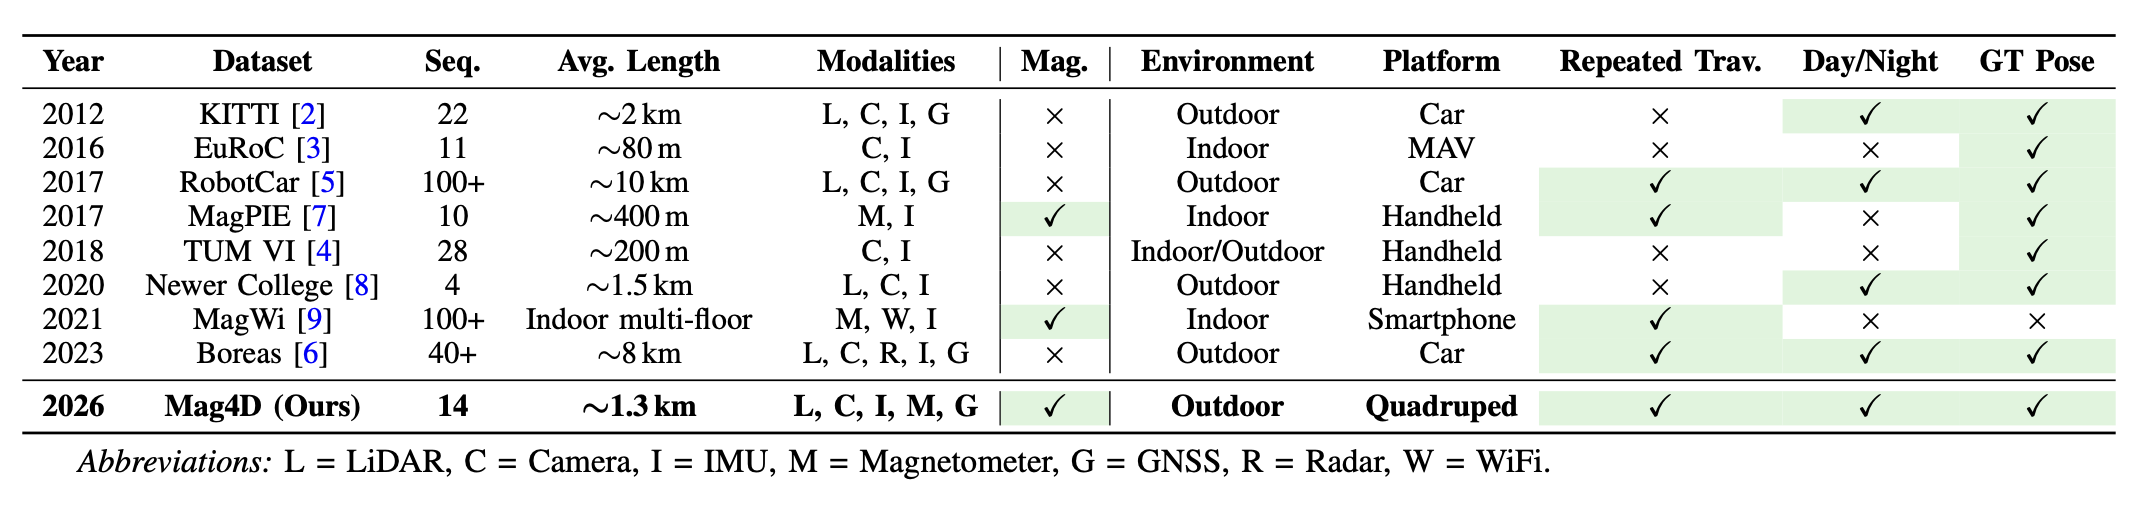
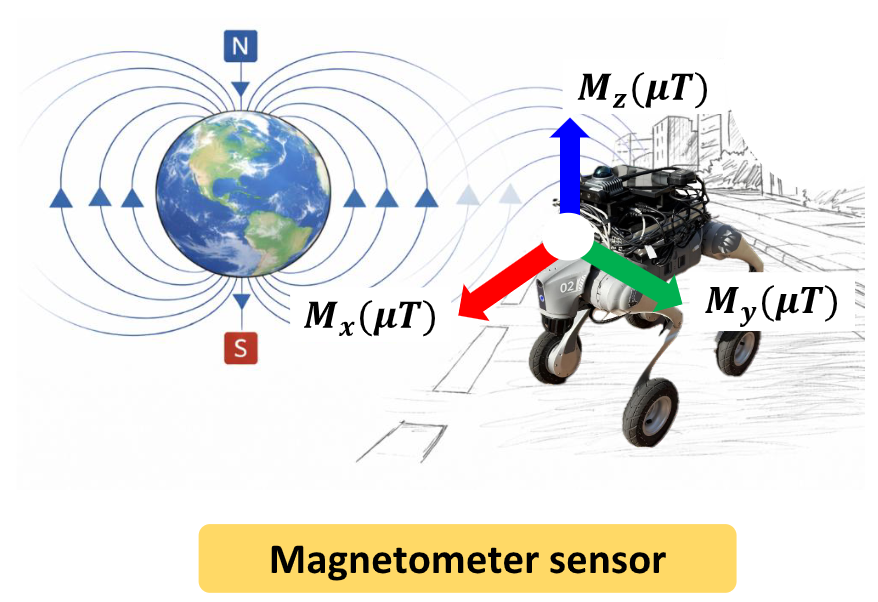
Towards Lifelong Outdoor Magnetic-Aware SLAM: A Multi-Modal Day-and-Night Geomagnetic Dataset

Venue/BookMM-SpatialAI Workshop, ICRA 2026 WSDateJun 1, 2026AuthorsBibhutibhusan Nayak*, Hyoseok Ju*, Giseop Kim†Notenon-archival
Figure for Towards Lifelong Outdoor Magnetic-Aware SLAM: A Multi-Modal Day-and-Night Geomagnetic Dataset
2026InternationalWorkshopAPRL

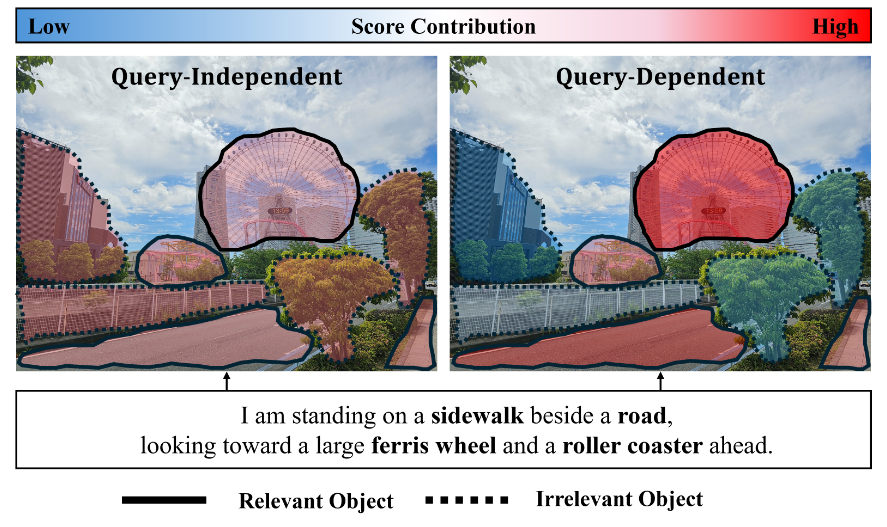
Two-Stage Hint–Object Alignment for Text-to-PointCloud Localization

Venue/BookMM-SpatialAI Workshop, ICRA 2026 WSDateJun 1, 2026AuthorsDoyeon Kim*, Giseop Kim†Notenon-archival
Figure for Two-Stage Hint–Object Alignment for Text-to-PointCloud Localization
2026InternationalConference

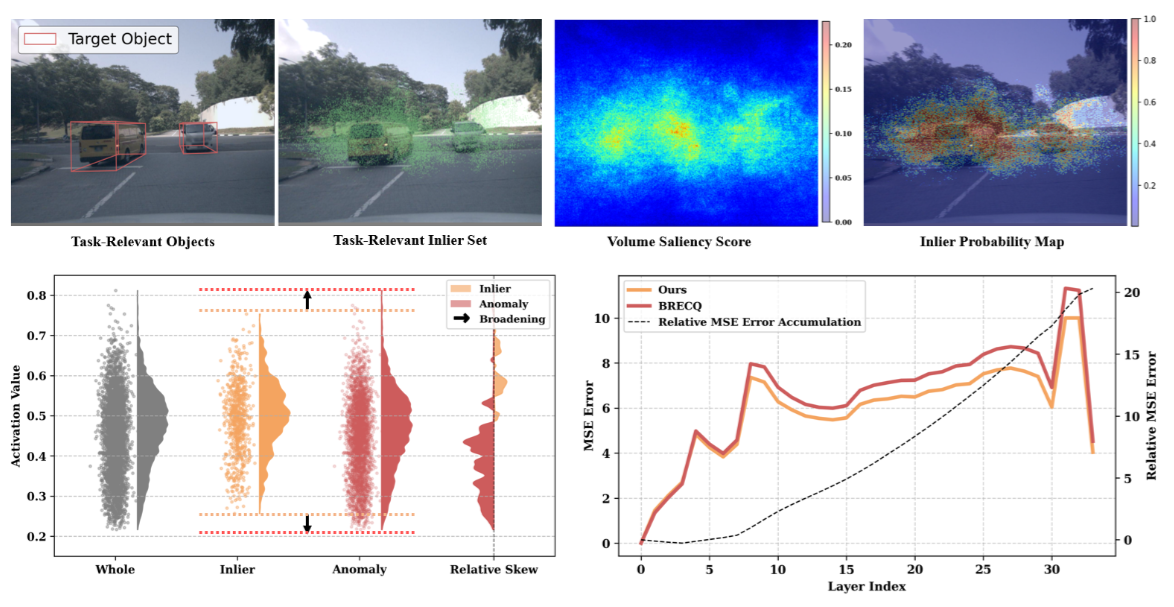
Inlier-Centric Post-Training Quantization for Object Detection Models

Venue/BookInternational Conference on Learning Representations (ICLR)DateApr 23-25, 2026AuthorsMinsu Kim*, Dongyeun Lee, Jaemyung Yu, Jiwan Hur, Giseop Kim, Junmo Kim†CollaborationKAIST
Figure for Inlier-Centric Post-Training Quantization for Object Detection Models
2026DomesticJournalAPRL

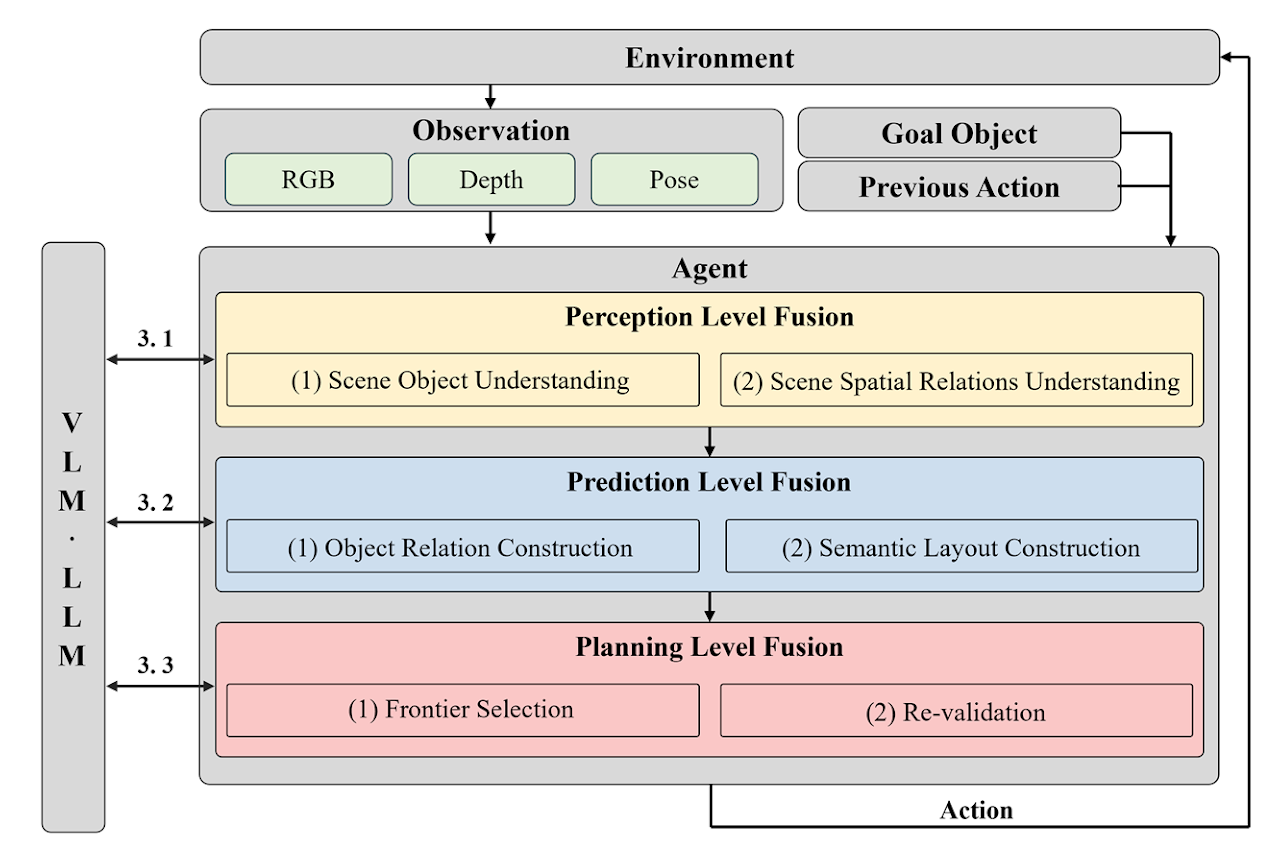
VLM 시대의 목표 객체 탐색을 위한 지식 융합 전략 서베이

Venue/Book한국자동차공학회 논문집InfoVol. 34, No. 1, pp. 119-131; ISSN 1225-6382; DOI 10.7467/KSAE.2026.34.1.119Authors서보건*, 김지선, 손준우, 박명옥, 김기섭†Collaborationsonnet.ai
Figure for VLM 시대의 목표 객체 탐색을 위한 지식 융합 전략 서베이
2026InternationalBookAPRL

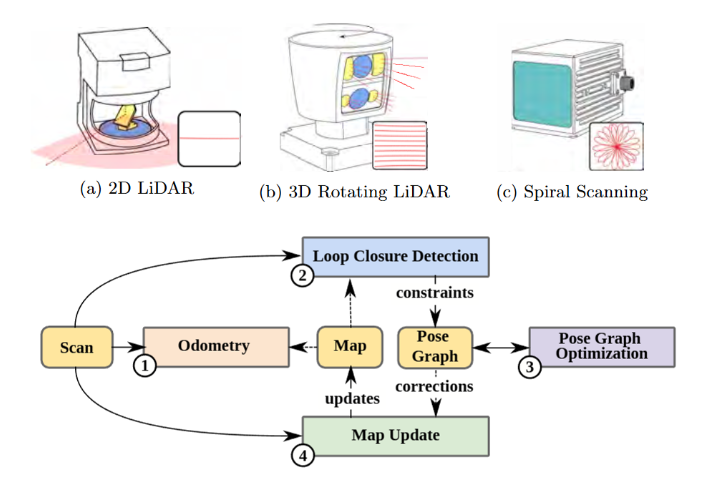
Chapter 8: LiDAR SLAM

Venue/BookSLAM Handbook (From Localization and Mapping to Spatial Intelligence)AuthorsJens Behley, Maurice Fallon, Shibo Zhao, Giseop Kim, Ji Zhang, Fu Zhang, Ayoung Kim
Figure for Chapter 8: LiDAR SLAM
2025
2025InternationalJournal

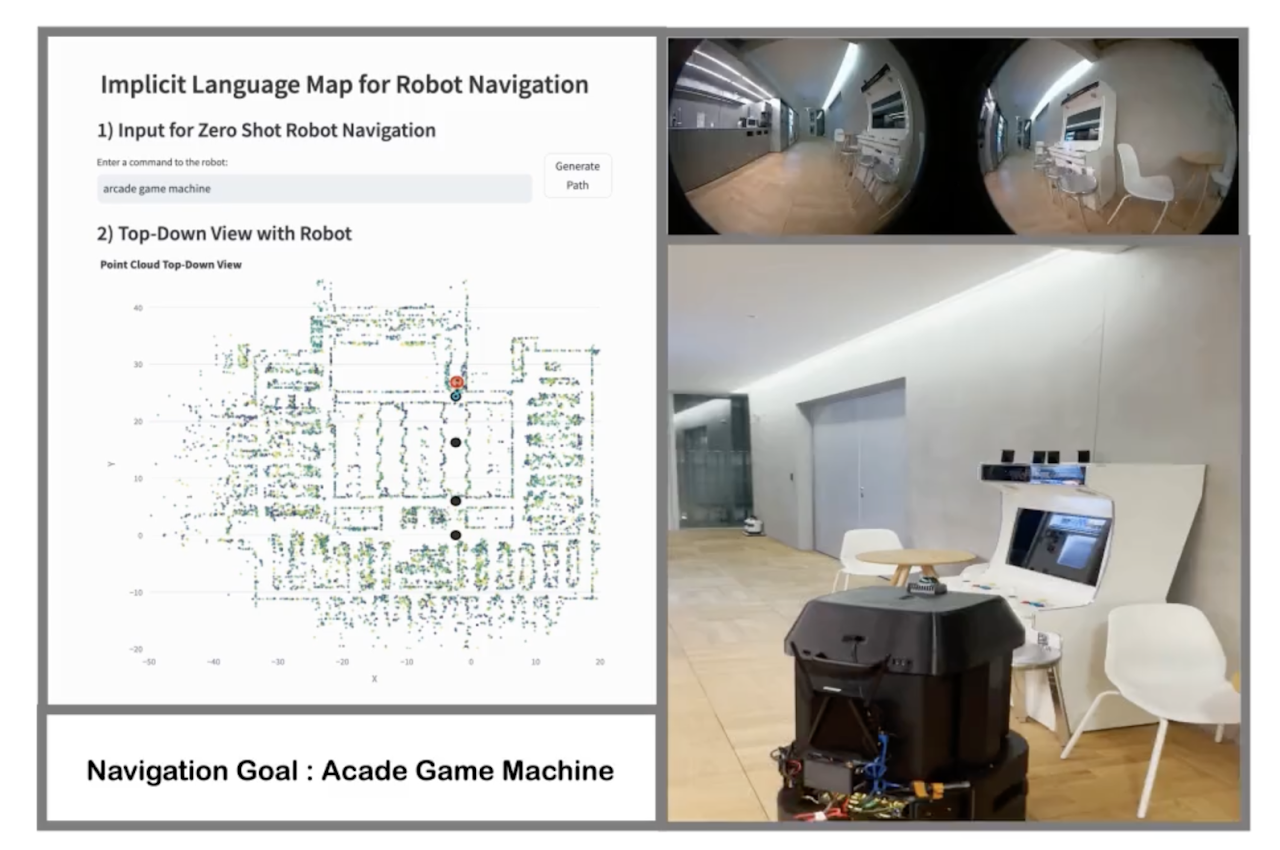
LAMP: Implicit Language Map for Robot Navigation

Venue/BookIEEE Robotics and Automation Letters (RA-L)InfoVol. 10, No. 12, pp. 12365-12372; ISSN 2377-3766; DOI 10.1109/LRA.2025.3619820AuthorsSibaek Lee*, Hyeonwoo Yu, Giseop Kim, Sunwook Choi†CollaborationSKKU, NAVER LABS
Figure for LAMP: Implicit Language Map for Robot Navigation
2025DomesticConferenceAPRL

도심환경에서의 변화에 강인한 LiDAR 위치인식 기법

Venue/Book대한전자공학회 학술대회DateNov 27-29, 2025Authors김기섭*†, 박명옥, 손준우Collaborationsonnet.ai
Figure for 도심환경에서의 변화에 강인한 LiDAR 위치인식 기법
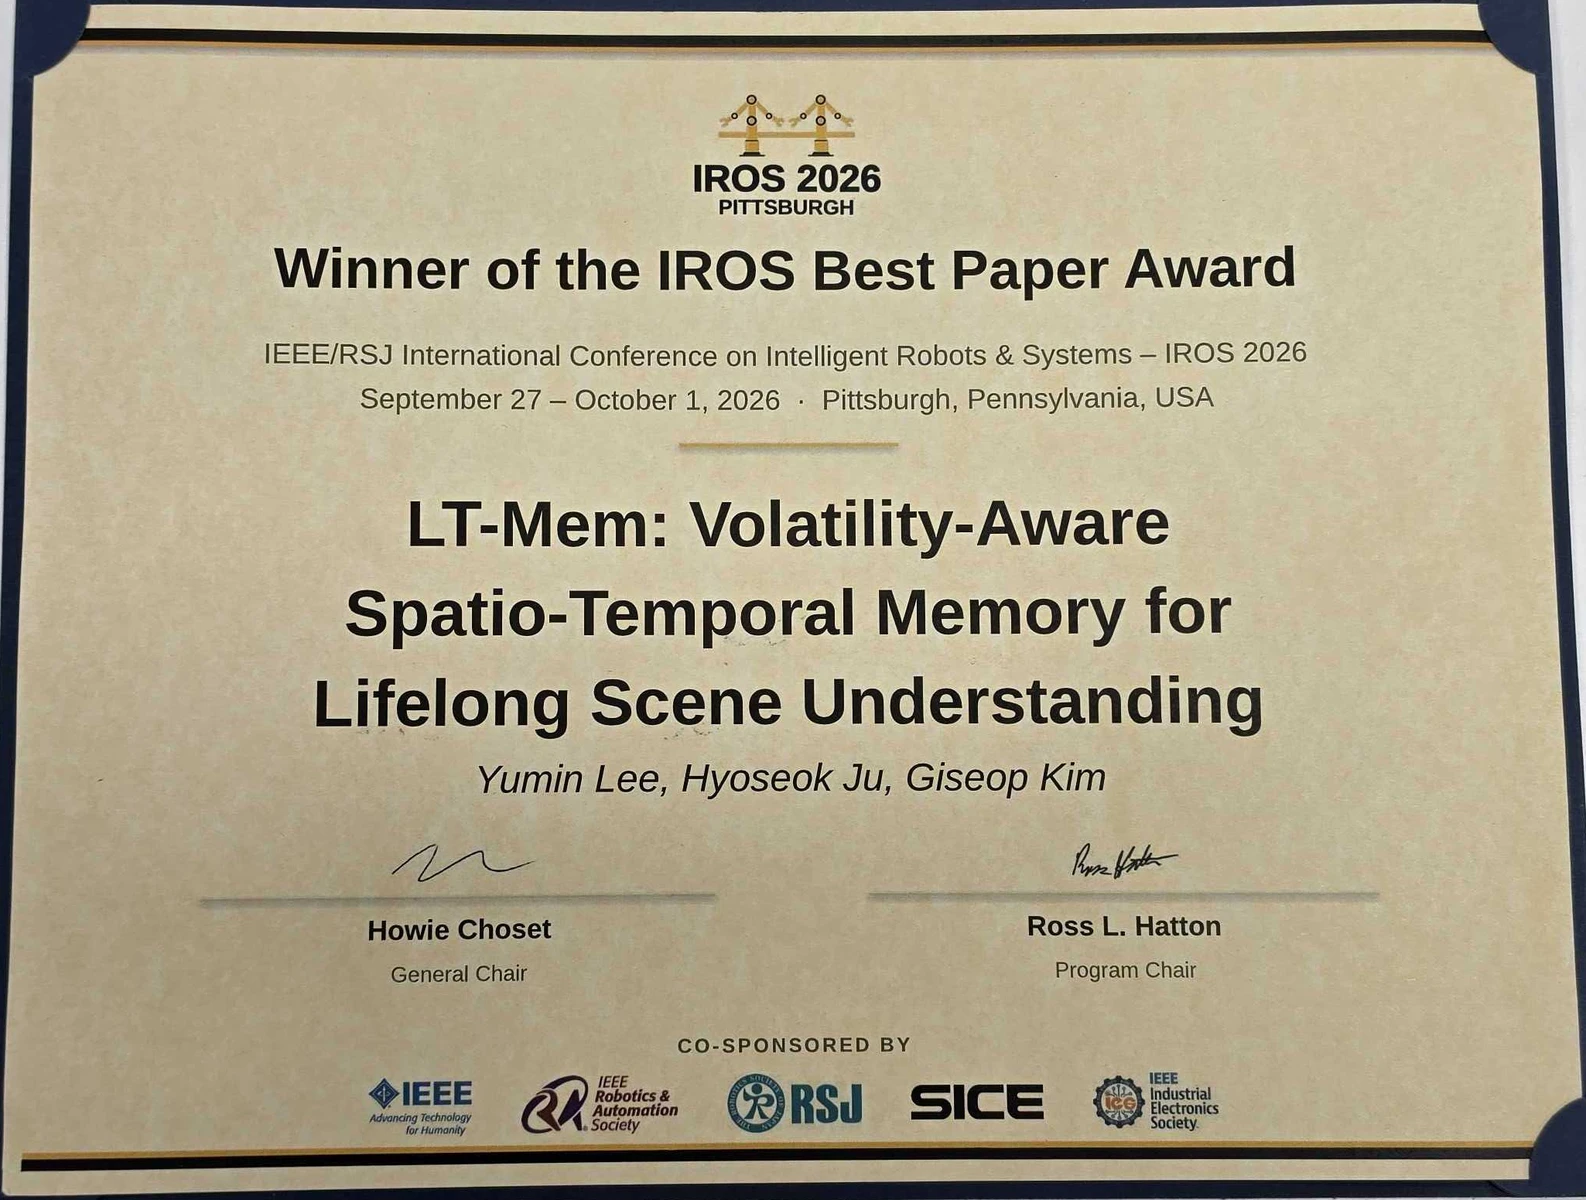
2025InternationalWorkshopAPRLAward

Towards Human-Like Instruction Navigation in Real-World

Venue/BookHuman-aware Embodied AI (HEAI), IROS 2025 WSDateOct 24, 2025AuthorsJiseon Kim*, Daeun Song, Bokeon Suh, Hyoseok Ju, Yumin Lee, Xuesu Xiao, and Giseop Kim†CollaborationGeorge Mason UniversityNotenon-archival; Best Poster Award
Figure for Towards Human-Like Instruction Navigation in Real-World
2025InternationalWorkshopAPRL

Where to Fuse in the VLM Era: A Survey on Integrating Knowledge into Object Goal Navigation

Venue/BookHuman-aware Embodied AI (HEAI), IROS 2025 WSDateOct 24, 2025AuthorsBokeon Suh*, Jiseon Kim, Giseop Kim†Notenon-archival
Figure for Where to Fuse in the VLM Era: A Survey on Integrating Knowledge into Object Goal Navigation
2025InternationalWorkshopAPRL

Towards Scale-consistent Deep Monocular Visual SLAM in Indoor Environments: A Dataset and Benchmark

Venue/BookThe 15th Workshop on Planning, Perception and Navigation for Intelligent Vehicles (PPNIV), IROS 2025 WSDateOct 20, 2025AuthorsHyoseok Ju*, Giseop Kim†Notenon-archival
Figure for Towards Scale-consistent Deep Monocular Visual SLAM in Indoor Environments: A Dataset and Benchmark
2025InternationalConference

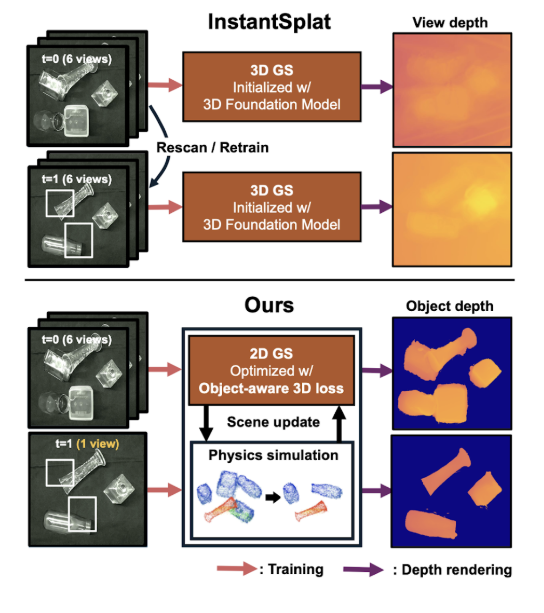
2D Gaussian Splatting-based Sparse-view Transparent Object Depth Reconstruction via Physics Simulation for Scene Update

Venue/BookIEEE/CVF International Conference on Computer Vision (ICCV)DateOct 19-23, 2025AuthorsJeongyun Kim*, Seunghoon Jeong*, Giseop Kim, Myung-Hwan Jeon, Eunji Jun, Ayoung Kim†CollaborationSNU
Figure for 2D Gaussian Splatting-based Sparse-view Transparent Object Depth Reconstruction via Physics Simulation for Scene Update
2024
2024InternationalJournal

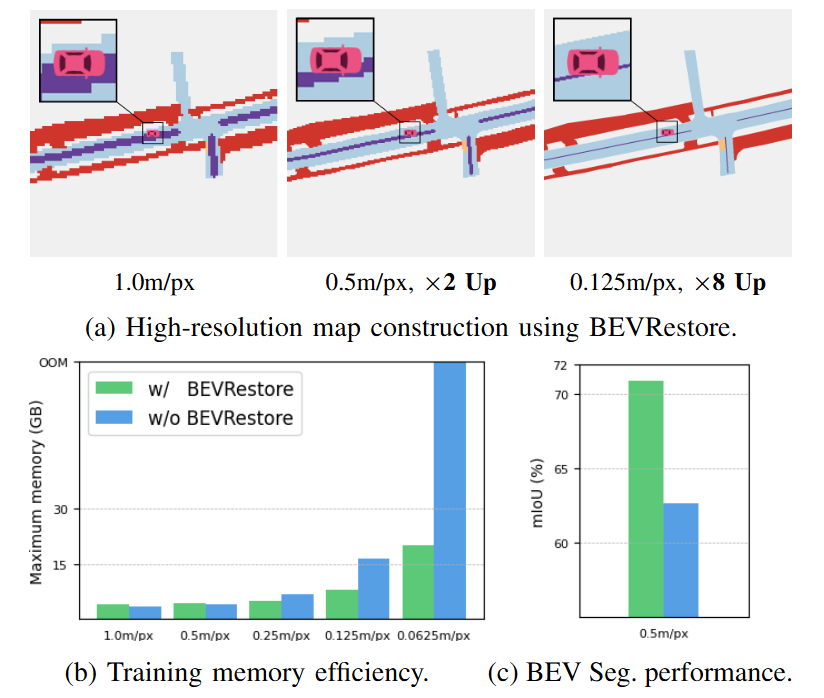
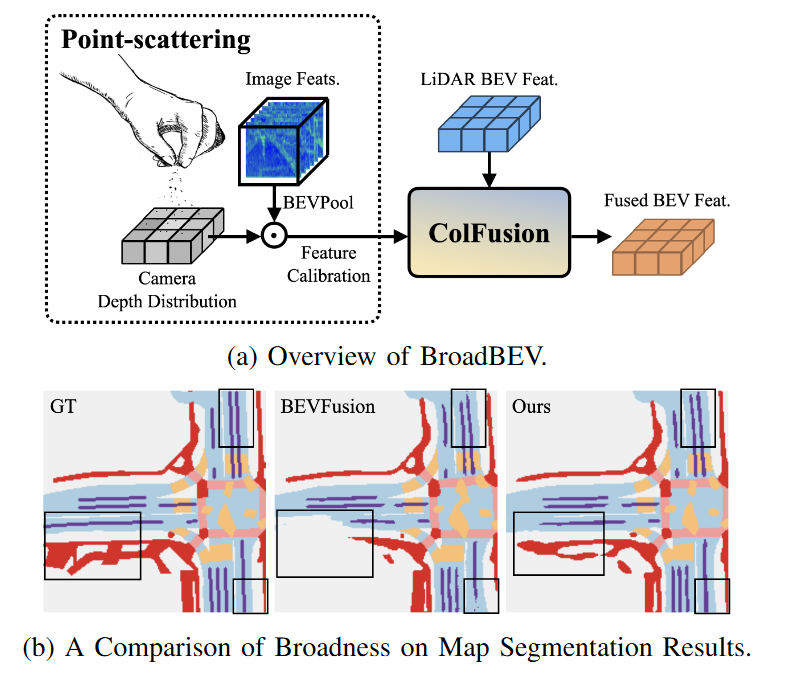
Addressing Diverging Training Costs Using BEVRestore for High-Resolution Bird's Eye View Map Construction

Venue/BookIEEE Robotics and Automation Letters (RA-L)InfoVol. 9, No. 11, pp. 10700-10707; DOI 10.1109/LRA.2024.3474477AuthorsMinsu Kim*, Giseop Kim, Sunwook Choi†CollaborationNAVER LABS
Figure for Addressing Diverging Training Costs Using BEVRestore for High-Resolution Bird's Eye View Map Construction
2024InternationalJournal

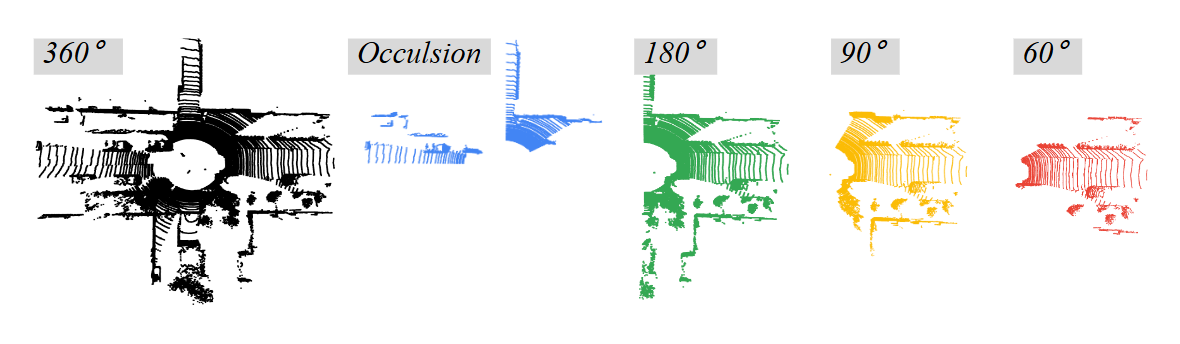
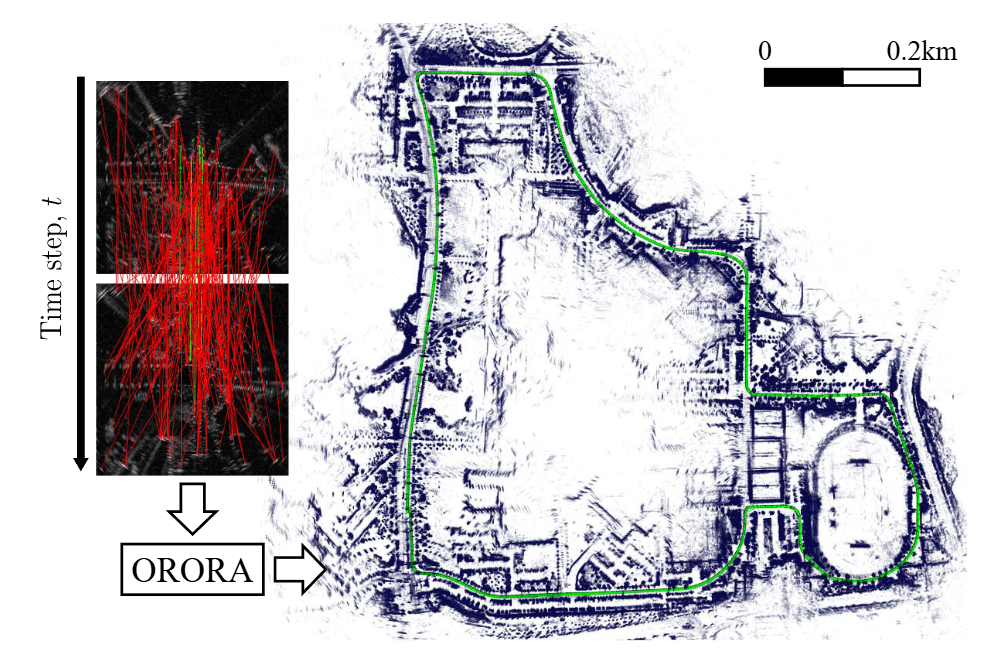
Narrowing Your FOV with SOLiD: Spatially Organized and Lightweight Global Descriptor for FOV-Constrained LiDAR Place Recognition

Venue/BookIEEE Robotics and Automation Letters (RA-L)InfoVol. 9, No. 11, pp. 9645-9652; DOI 10.1109/LRA.2024.3440089AuthorsHogyun Kim*, Jiwon Choi, Taehu Sim, Giseop Kim, Younggun Cho†CollaborationInha Univ
Figure for Narrowing Your FOV with SOLiD: Spatially Organized and Lightweight Global Descriptor for FOV-Constrained LiDAR Place Recognition
2023
2023InternationalJournal

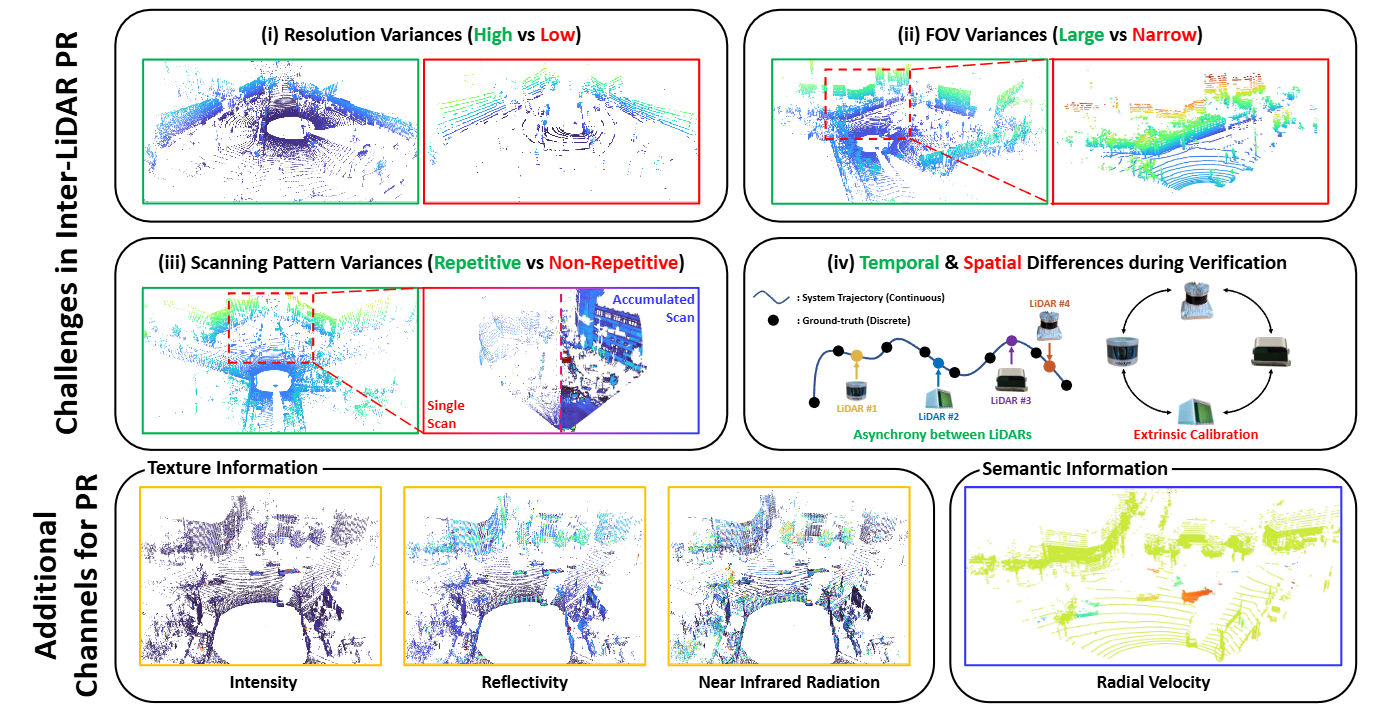
HeLiPR: Heterogeneous LiDAR Dataset for Inter-LiDAR Place Recognition under Spatiotemporal Variations

Venue/BookThe International Journal of Robotics Research (IJRR)InfoVol. 43, No. 12, pp. 1867-1883; DOI 10.1177/02783649241242136AuthorsMinwoo Jung*, Wooseong Yang, Dongjae Lee, Hyeonjae Gil, Giseop Kim, Ayoung Kim†CollaborationSNU
Figure for HeLiPR: Heterogeneous LiDAR Dataset for Inter-LiDAR Place Recognition under Spatiotemporal Variations
2022
2022InternationalJournal

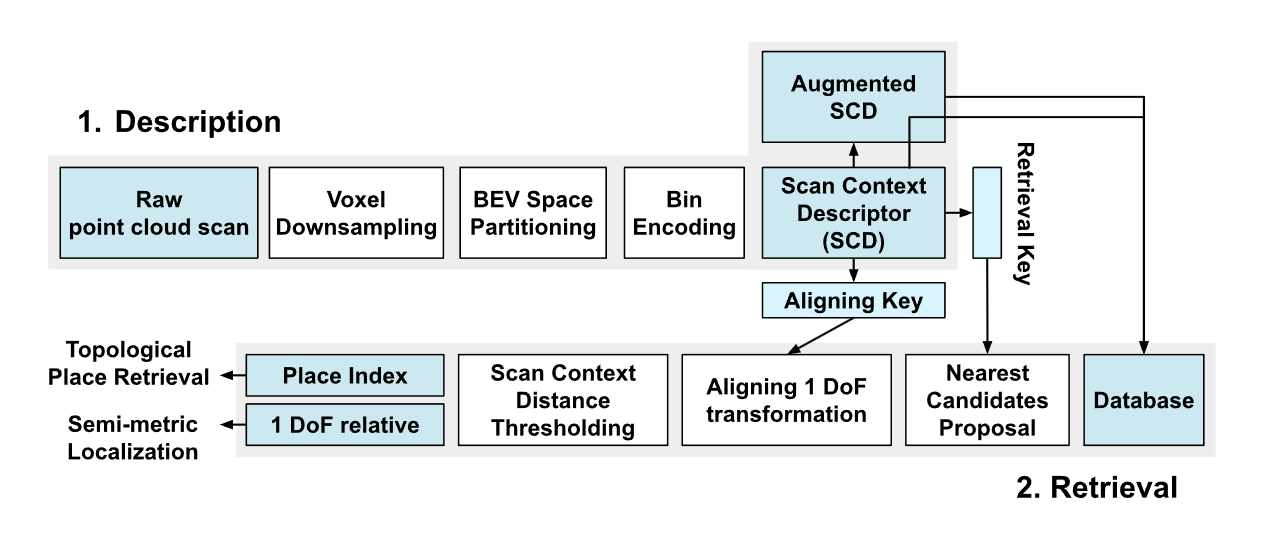
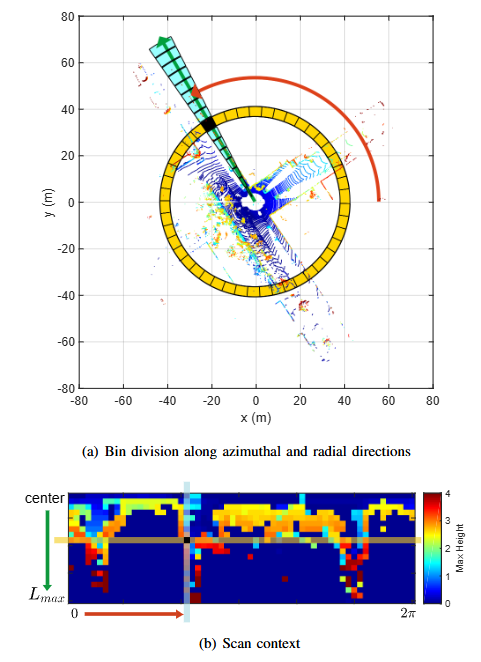
Scan Context++: Structural Place Recognition Robust to Rotation and Lateral Variations in Urban Environments

Venue/BookIEEE Transactions on Robotics (T-RO)InfoVol. 38, No. 3, pp. 1856-1874; DOI 10.1109/TRO.2021.3116424AuthorsGiseop Kim*, Sunwook Choi, Ayoung Kim†CollaborationNAVER LABS
Figure for Scan Context++: Structural Place Recognition Robust to Rotation and Lateral Variations in Urban Environments
2022InternationalJournal

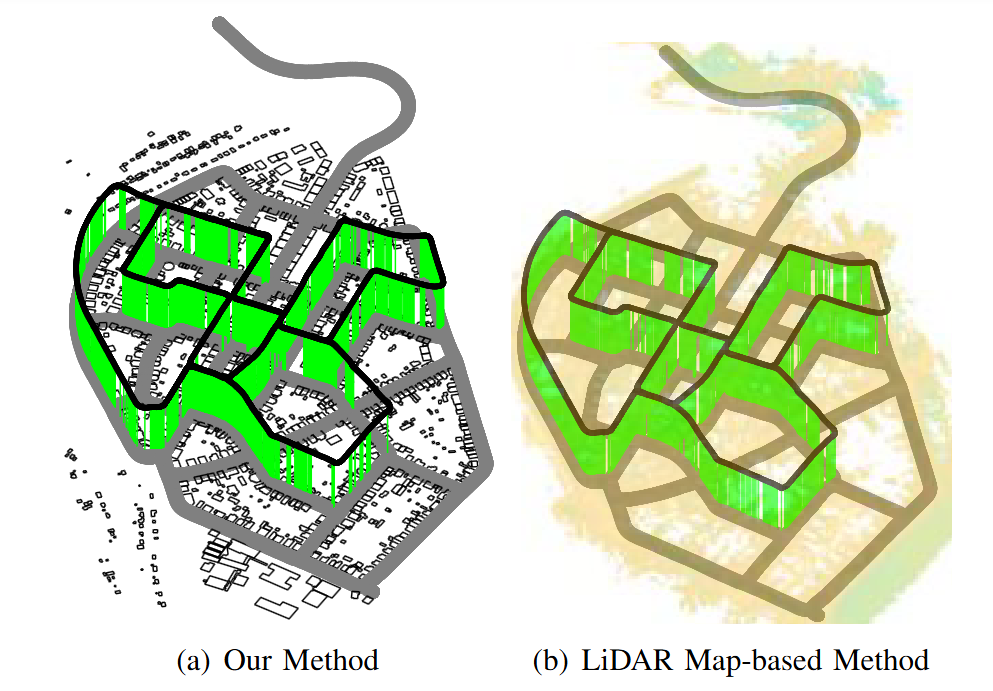
OpenStreetMap-based LiDAR Global Localization in Urban Environment without a Prior LiDAR Map

Venue/BookIEEE Robotics and Automation Letters (RA-L)InfoVol. 7, No. 2, pp. 4999-5006; DOI 10.1109/LRA.2022.3152476AuthorsYounghun Cho*, Giseop Kim, Sangmin Lee, Jee-Hwan Ryu†
Figure for OpenStreetMap-based LiDAR Global Localization in Urban Environment without a Prior LiDAR Map
2020
2019
2019InternationalWorkshop

CNN-based Approach for Opti-Acoustic Reciprocal Feature Matching

Venue/BookICRA WorkshopDateMay 24, 2019AuthorsHyesu Jang*, Giseop Kim, Yeongjun Lee, Ayoung Kim†
2019InternationalJournal

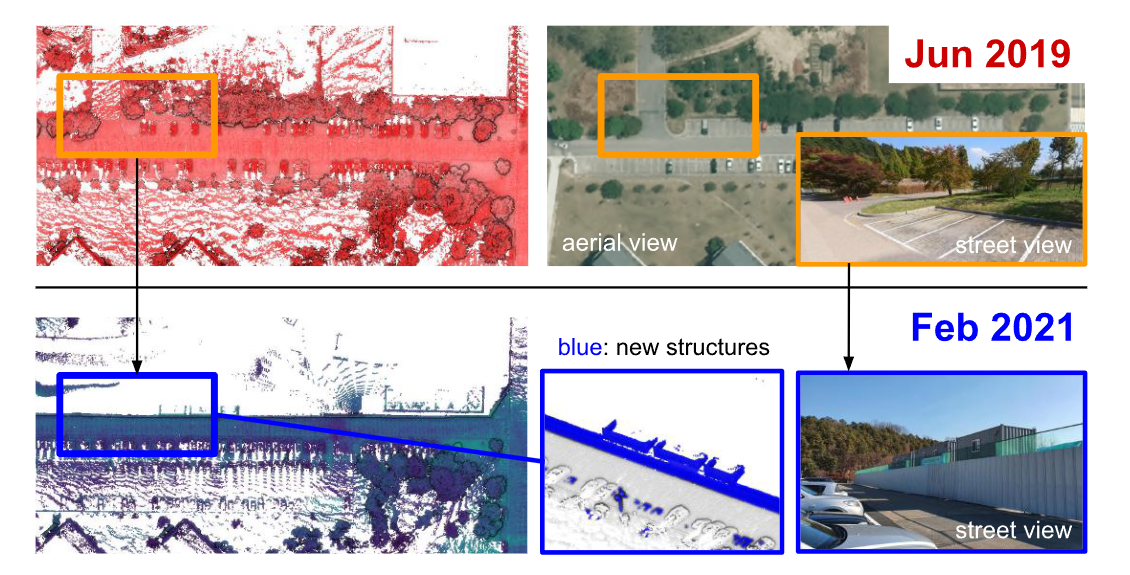
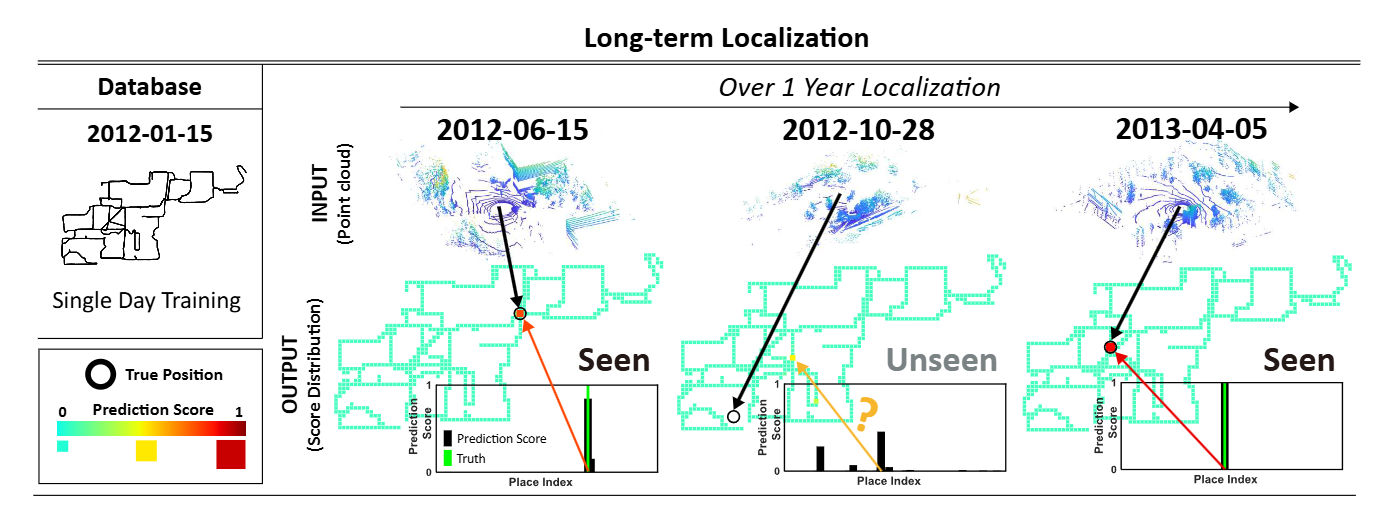
1-Day Learning, 1-Year Localization: Long-term LiDAR Localization using Scan Context Image

Venue/BookIEEE Robotics and Automation Letters (RA-L)InfoVol. 4, No. 2, pp. 1948-1955; DOI 10.1109/LRA.2019.2897340AuthorsGiseop Kim*, Byungjae Park, Ayoung Kim†
Figure for 1-Day Learning, 1-Year Localization: Long-term LiDAR Localization using Scan Context Image
2018
2018InternationalWorkshop

Learning Scan Context toward Long-term LiDAR Localization

Venue/BookICRA WorkshopDateMay 25, 2018AuthorsGiseop Kim*, Byungjae Park, Ayoung Kim†